TECHNOLOGY EXPLAINER
Legged and Inspection Robots
— How four-legged walking works, the flow of inspection work, what explosion-protection certification (ATEX, IECEx) means and covers, and the limits
Dog-like four-legged robots are starting to be used for inspection in factories, power stations and chemical plants. But hearing that one has “gained explosion-protection certification” is not a reason to think it is safe to use anywhere. Explosion protection has zones (the place), categories (the equipment), gas groups and a scope of certification, and Japan has its own verification system. This article assumes no background in robots or explosion protection. In order, it covers (1) why robots walk on legs, (2) the companies’ stated numbers for leading models (Spot and ANYmal), (3) how to read battery and runtime figures, (4) the flow of inspection work, (5) the idea of explosion protection, zones, and how ATEX, IECEx and Japan’s type verification relate, and (6) limits and a materials view, with figures and small calculations. Numbers are the company’s stated value and we do not rank models. Certifications are written as the company’s statement; we did not see the certificates themselves.
- The short version / what to know first / where this sits in the series
- Why walk on legs: choosing footholds, and research on learned walking
- Leading models as the makers state them: Spot and ANYmal
- Reading battery and runtime
- The flow of inspection work, and how to read claims of effect
- What explosion protection is: conditions for an explosion, zones, categories
- ATEX, IECEx and Japan’s type verification: reading the scope of a certificate
- Limits of inspection robots
- Limits, what could not be confirmed, and summary
- How to read the yardsticks and standards
- Glossary
- References (primary sources)
- Claim-to-source audit
Sourced = stated in an official source (company page or specification sheet, EU law, standards body, circular, paper), with a link. Company claims and statements are marked as such
Our calculation = a value this article computed from stated assumptions
Not yet confirmed = standards in development, specifications “coming soon”: anything not yet settled
Our readings of structure and of materials are labelled commentary. An Inference is shown in bold. Every analogy comes with its limit.
Robot numbers are the company’s stated value, and the test conditions are sometimes not given. “Explosion-protection certification”, “track record” and “effect of deployment” are company statements; we did not check the certificates (certification body, number, scope, temperature class and so on). We do not rank numbers from different models. This is a general explainer. It does not judge or advise on buying a model, on whether a robot may be used in an explosive area, or on legal compliance. To use equipment in an explosive area, consult the scope of the certificate, the site’s area classification, the law, and qualified experts (certification bodies and explosion-protection specialists). This field moves fast, so each status carries a check date (25 October 2026).
1. The short version / what to know first / where this sits in the series
- Legs are a shape for working in equipment built for people, with stairs and open-grating floors. Boston Dynamics’ Spot is stated at 32.7 kg, a payload of 14 kg, a top speed of 1.6 m/s and an average runtime of 90 minutes Sourced[Ref. 1]. The price is battery use: even standing still, it keeps drawing power (about 188 W, computed from Spot’s stated numbers) Our calculation.
- “Explosion-protection certification” has a scope by equipment, gas type and area class. ANYbotics describes ANYmal X as “ATEX and IECEx certified up to Zone 1 IIB” (the company’s statement) Sourced[Ref. 6]. Zone 1 is “a place where an explosive atmosphere is likely to occur in normal operation occasionally”; whether it applies to dust or to more easily ignited gases could not be confirmed on the page [Ref. 7].
- Japan has a type-verification system for explosion-protected electrical equipment. Article 44-2 of the Industrial Safety and Health Act requires verification by a registered body, and a circular of the Ministry of Health, Labour and Welfare (5 March 2020) sets out the conditions under which IECEx test reports and the like can be used as application documents Sourced[Ref. 11]. A foreign certificate does not necessarily mean it can be used in Japan as it is.
You need no background. A robot is a combination of sensing, thinking (control and intelligence) and moving (actuators), and an actuator is the robot’s muscle (motor plus reducer). Explosion protection means making sure that electrical equipment does not become the spark or heat that ignites flammable gas or dust where it is present. A zone classifies a place; a category classifies equipment.
This article collects four-legged inspection robots and how to read explosion-protection certification. Two-legged humanoids are in the article on humanoid robots; how to read standards in the article on robot safety standards; learned walking in the articles on imitation and reinforcement learning and on robot simulation and digital twins; and batteries in the articles on power sources for robots and drones and on thermal runaway and battery safety.
2. Why walk on legs: choosing footholds, and research on learned walking
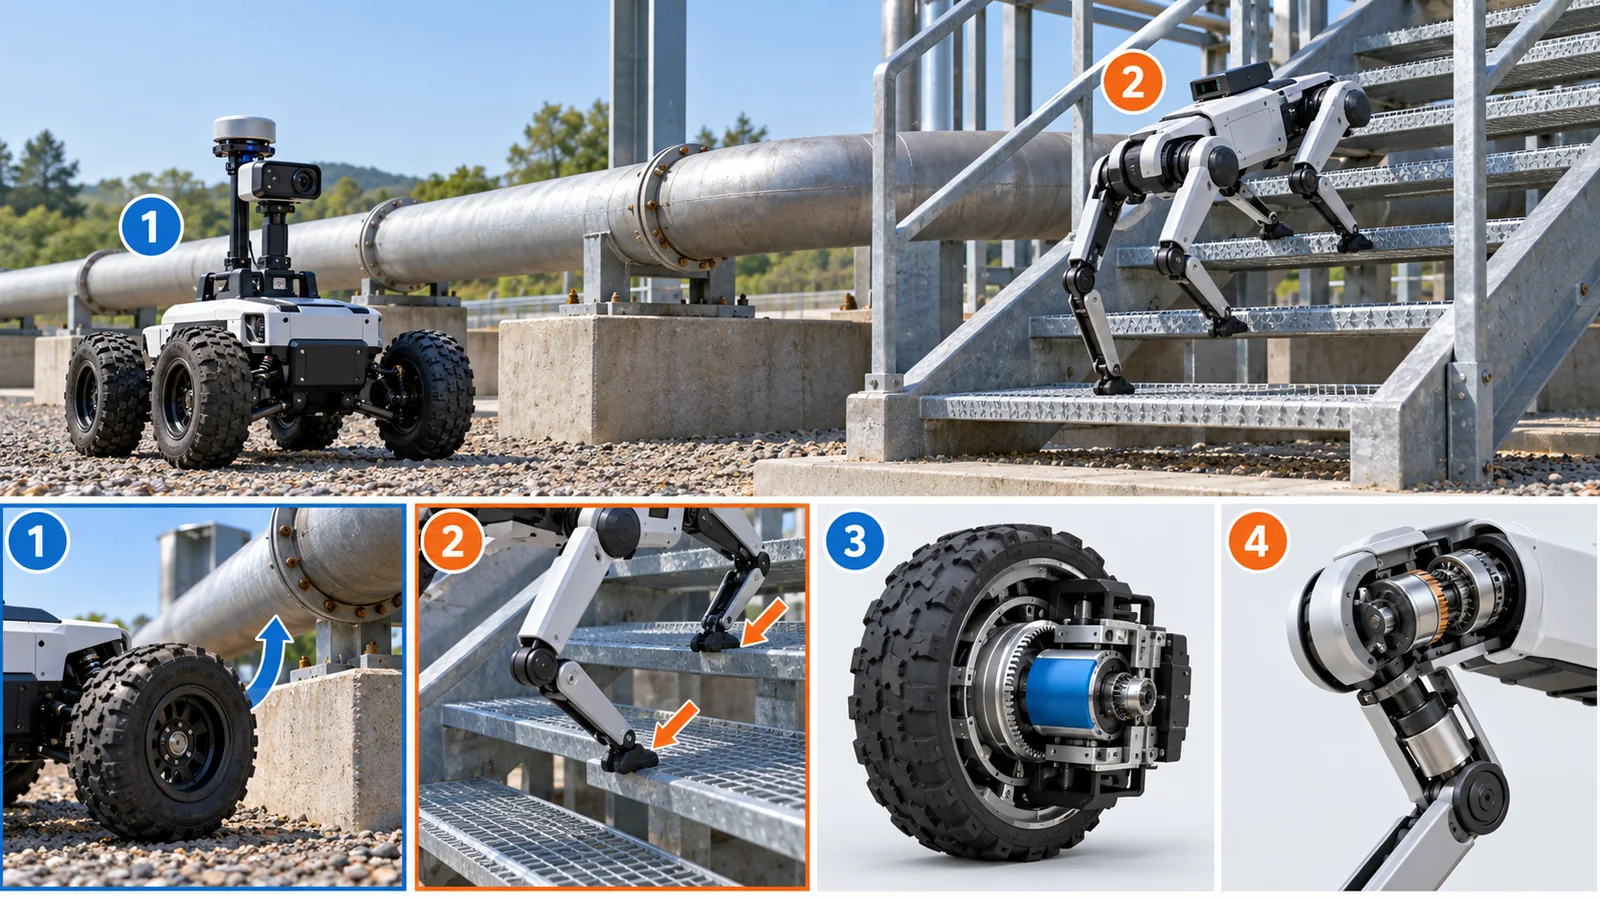
Wheels run quietly and fast on a continuous flat surface. Legs can pick discrete footholds and move on. In equipment built for people (stairs, open-grating floors, steps, narrow spaces) that helps (a general explanation; Fig. 2). ANYbotics describes ANYmal as “safe on open grated stairs”, able to “crawl in low positions” and working “on wet and bumpy terrain” (the company’s statements) [Ref. 5].
Original SVG, detailed explanation and sources
Original SVG reference: Conceptual diagram (vector drawing). The advantage of legs: choosing where to step. A general explanation of the difference between wheels and legs (commentary). That ANYmal is described as usable on open grated stairs and the like is from the company page Sourced[Ref. 5]. The drawings only suggest shapes, not real machines.
Research on learned walking
- The paper introducing ANYmal, by Hutter and co-authors, is a 2016 IROS paper [Ref. 18] (we did not check its text).
- A 2019 paper by Hwangbo and co-authors showed a way to give a real legged robot (ANYmal) precise, efficient movements with control learned in simulation (as summarized by the editors of Science Robotics) Sourced[Ref. 14].
- A 2020 paper by Lee and co-authors showed that a learning-based controller lets ANYmal cross challenging natural terrain [Ref. 15].
- A 2022 paper by Miki and co-authors lists conditions that degrade what sensors see (snow, vegetation and water looking like obstacles; depth perception degraded by lighting, dust or fog) and reports a controller that integrates perception of the surroundings with the body’s own sensing and completed an hour-long hike in the Alps in the time recommended for human hikers [Ref. 16].
Traditionally, people wrote equations for walking and tuned them. Learning-based methods use the result of practising at scale in simulation, falling many times (a little like learning to ride a bicycle by practice instead of from a manual. Limit of the analogy: the robot practises not with a real body but inside a simulation). Even so, it is not necessarily strong outside what it practised. As the Miki paper points out, scenes where sensors cannot see real terrain correctly remain a challenge (commentary).
3. Leading models as the makers state them: Spot and ANYmal
The numbers below are companies’ stated values from their pages and specification sheets. Many lack test conditions, and they do not rank the models.
From the Spot (Boston Dynamics) specification sheet
- Size and weight: length 1100 mm, width 500 mm, walking height 610 mm (default), weight 32.7 kg (with battery)
- Movement: maximum speed 1.6 m/s, maximum slope +/-30 deg, maximum step height 300 mm
- Battery: 564 Wh, average runtime 90 min, standby 180 min, recharge 60 min (with the note that “runtime may vary depending on payloads and environmental factors”)
- Environment: IP54, operating temperature -20 to 55 C (with the note that the robot must be powered on at a minimum of 0 C)
- Payload: up to 14 kg (mounting area 850 x 240 x 270 mm)
These are the entries in the sheet (updated 22 May 2024) Sourced[Ref. 1]. The sheet also says “designed according to ISO 12100 for risk assessment and reduction methodology and IEC 60204-1 for electrical safety” and “emergency stop meets ISO 13850”. These describe the design method and component standards; they do not mean the whole robot “conforms” to a particular product-safety standard (commentary; ISO 12100 is the basic standard on risk assessment and risk reduction [Ref. 13]). A search for “ATEX” on Boston Dynamics’ own site returned 0 results [Ref. 4] (this means we could not find an official statement on explosion protection for Spot).
From the ANYmal and ANYmal X (ANYbotics) product pages
- ANYmal: IP67; a standard inspection payload (20x optical zoom camera, thermal camera -40 to 550 C, ultrasonic microphone 0 to 384 kHz, light, 360 deg LiDAR); an additional 10 kg payload; normal walking speed 0.75 m/s; battery 90 min; 100 min for a 70% quick charge; 3 h for a full charge; “walking range about 2 km (90 to 120 min) per charge” Sourced[Ref. 5]
- ANYmal X: “ATEX and IECEx certified up to Zone 1 IIB” and “IP67” (the company’s statements), thermal camera -10 to +400 C, and a gas-concentration sensor as an optional payload. The page says that 2026 specifications are “coming soon” Sourced Not yet confirmed[Ref. 6]
4. Reading battery and runtime
Dividing the numbers shows what the stated values mean (Fig. 4).
- Spot: with a 564 Wh battery and an average runtime of 90 minutes, the average power is 564 / 1.5 = 376 W. With a standby time of 180 minutes it is 564 / 3 = 188 W Our calculation. So even standing still without walking, it uses about 188 W. This is probably because the joint motors keep producing force to hold up the body (commentary).
- ANYmal: from “2 km in 90 to 120 minutes”, the average speed is 2000 / 5400 = 0.37 m/s or 2000 / 7200 = 0.28 m/s Our calculation. It is slower than the normal walking speed of 0.75 m/s because it is an average that includes time spent stopped to measure and so on (commentary; the page gives no breakdown).
“90 minutes” is an average that changes with load, terrain, temperature and how the robot is driven (Spot’s specification sheet notes that conditions change it). The work of inspection (walking, stopping, measuring, communicating) is not the same as time spent walking. Battery capacity and weight trade off against runtime and payload (see the series article on power sources for robots and drones).
5. The flow of inspection work, and how to read claims of effect
The job of an inspection robot is not walking; it is collecting data again and again, at fixed places, under the same conditions. Fig. 5 sets out the flow. For inspection uses, Boston Dynamics lists perimeter checks (safety), thermal (hot spots), visual (reading gauges) and acoustic (air leaks and vibration) [Ref. 3]. ANYbotics says visual and thermal cameras, an ultrasonic microphone, a light and LiDAR are standard, and that sensors for gas concentration and acoustic imaging can be added (all descriptions on the companies’ pages) [Ref. 5].
On effect, the ANYbotics page carries a customer remark that regular thermal readings reduced maintenance interventions and raised production uptime by 1.5% “directly attributable to ANYmal” Sourced[Ref. 5]. This is a customer remark posted on a company page; how it was measured, the period covered, the influence of other factors and any independent verification could not be confirmed. On the research side, an analysis of the US DARPA Subterranean Challenge (2018 to 2021) sets out where technology for underground inspection and exploration stands and what remains hard [Ref. 17] (we did not check its text).
This is inaccurate. The robot collects data along set routes. Looking at the data and deciding what to do is up to people (step 5 in Fig. 5). What a robot can measure (heat, sound, gas concentration and so on) differs from what a person notices on site by seeing, touching and smelling. And introducing a robot creates new work in communications, charging, route setting and maintenance (commentary).
6. What explosion protection is: conditions for an explosion, zones, categories
Chemical plants and oil and gas facilities have places where flammable gas, vapour or dust is present in the air. There, electrical equipment must not become the ignition source through sparks or hot surfaces. That is explosion protection. An explosion needs fuel, oxygen and an ignition source together, and explosion protection works by not becoming an ignition source or by keeping an explosion inside the equipment (a general explanation; commentary; Fig. 6). The IECEx standards list gives examples of protection types as standards of the IEC 60079 series, such as flameproof enclosures (d), pressurized enclosures (p), increased safety (e), intrinsic safety (i) and encapsulation (m) Sourced[Ref. 10].
Zones and categories
Annex I of the EU Directive 1999/92/EC classifies places, for gas, vapour and mist, as follows. Zone 0 is a place where an explosive atmosphere is present continuously, for long periods or frequently; Zone 1 is a place where one is likely to occur in normal operation occasionally; Zone 2 is a place where one is not likely to occur in normal operation but, if it does, will persist for a short period only (for dust the zones are 20 to 22) Sourced[Ref. 7]. For equipment, Annex I of Directive 2014/34/EU defines category 1 (very high level of protection, for areas where explosive atmospheres are present continuously, for long periods or frequently), category 2 (high level, for areas where they are likely to occur occasionally) and category 3 (normal level, for areas where they are unlikely) [Ref. 8]. The wording of zones and categories corresponds, so one can say that equipment of category 2 is generally used in a Zone 1 place (this article’s arrangement; legal details were not checked).
“Zone 1” is the class of place (where gas is likely to occur occasionally), and “IIB” is one gas group (we did not check the definition of the groups). So “certified up to Zone 1 IIB” means a certification covering that class of place and that gas group. The ANYbotics page does not say whether it applies to dust areas or to groups more easily ignited than IIB. It is necessary to check, site by site, whether the scope of the certification (class of place, gas group, temperature class, certified equipment configuration) matches the classification of the place where it will be used (commentary).
7. ATEX, IECEx and Japan’s type verification: reading the scope of a certificate
Explosion-protection certification comes from several schemes (Fig. 8).
- ATEX: the EU directives: Directive 2014/34/EU on equipment and Directive 1999/92/EC on the workplace. Equipment placed on the EU market carries the CE marking once it meets the requirements. The directive does not apply to seagoing vessels and mobile offshore units, nor to equipment on board them (Article 1) Sourced[Ref. 8]. ANYbotics also says ANYmal X has a record offshore “on fixed and floating platforms” (the company’s statement) [Ref. 6]; how this relates to maritime rules was not checked here.
- IECEx: a certification system for equipment for explosive atmospheres, set up by the IEC in 1996. Based on standards such as the IEC 60079 series, certification bodies around the world (ExCBs) issue certificates and test reports (ExTRs) Sourced[Ref. 9, 10].
- Japan: explosion-protected electrical equipment must, under Article 44-2(1) of the Industrial Safety and Health Act, undergo type verification by a registered body. The Ministry of Health, Labour and Welfare’s circular (Kian-hatsu 0305 No. 1, 5 March 2020) says an IECEx ExTR can be treated as the document recording prior test results in the application, and that, where an IECEx certification body also serves as an ATEX notified body, its ATEX test report can be treated the same way if four conditions are met (it concerns the type applied for; it was properly issued under the ATEX directive; it covers everything an ExTR must contain; it is in Japanese or English) Sourced[Ref. 11].
This is inaccurate. What the circular shows is that a foreign test report can sometimes be used in an application for Japanese type verification; the verification itself is done by Japanese registered bodies. Moreover, how a moving legged robot is treated as “explosion-protected electrical equipment” in Japan could not be confirmed here. Check with a certification body, a verification body and experts before use.
8. Limits of inspection robots
- Battery: runtime is about 90 minutes (stated). The range of inspection depends on where the docks are (ANYmal is said to extend its reach with multiple docks) [Ref. 5].
- Environment: Spot is -20 to 55 C and IP54 (a protection class for dust and water; we did not check its definition); ANYmal is IP67 (company’s stated). At low temperature there is a condition on starting (Spot).
- Terrain and sensing: snow, vegetation, water, reflective surfaces, lighting and fog degrade what sensors see [Ref. 16].
- Safety around people: ISO 25785-1, the safety standard for legged industrial robots, is on the ISO page of 25 October 2026 a committee draft (in development) Not yet confirmed. Explosive atmospheres are not among the hazards it covers [Ref. 12]. So legged robots working in explosive areas are in a field where both robot safety standards and explosion-protection certification are still being built out (commentary; see the series article on robot safety standards).
- Falls: there is the impact of a fall, and the effort of getting a fallen robot back up (see the rough estimate in the series article on humanoid robots).
The protection types (Fig. 6) bear directly on the choice of materials. A flameproof enclosure (d) assumes a thick metal housing with precisely machined gaps, so that an explosion does not send flame outside (commentary). Sealing (IP67) relies on the durability of seal materials (elastomers) to keep out dust and water. Plastic outer shells can accumulate static charge, which is why the IECEx standards list includes “Electrostatic hazards: guidance” (IEC/TS 60079-32-1) Sourced[Ref. 10]. Plastics and surface treatments that do not charge easily are a materials issue for explosion-protected equipment (commentary; the actual requirements are in the standard’s text, which we did not check). A walking robot has motors, reducers, batteries and electronics, many parts that can heat or spark, so the design collides: wanting to shed heat and wanting to seal (Inference: which protection type ANYmal X uses for which part was not confirmed in the sources above).
Spot’s specification sheet gives an operating temperature of -20 to 55 C but notes that the robot must be powered on at 0 C or above [Ref. 1]. At low temperature, the performance of lithium-ion batteries (the power and capacity available) is known to fall (see the series article on the basics of lithium-ion batteries), and the viscosity of lubricants changes (commentary). The ANYmal page advertises a rugged design with impact protection (IP67) (the company’s statement) [Ref. 5]. The friction of the foot-sole material, such as rubber, decides whether the robot can walk without slipping on wet gratings and stairs (Inference: the actual sole materials were not confirmed in official materials).
9. Limits, what could not be confirmed, and summary
(1) Certificates and the scope of certification
For ANYmal X, the ATEX and IECEx certificates, certification bodies and numbers, temperature class, applicability to dust, and the certified configuration could not be confirmed. “Up to Zone 1 IIB” is the company’s statement.
(2) Model numbers
Spot’s specification sheet was updated on 22 May 2024 and may differ from the current model. The weight of ANYmal could not be confirmed, and the 2026 specifications of ANYmal X were “coming soon”.
(3) Treatment in Japan
Whether a legged robot is subject to Japan’s type verification of “explosion-protected electrical equipment”, and in what class, could not be confirmed. The circular is dated 5 March 2020, and later amendments were not checked.
(4) What is not covered
Other legged and inspection robots, underwater and underground inspection, inspection by drones, and the requirements of each part of IEC 60079 are not covered. ASTM standards are not covered.
- Legs can choose footholds, so a robot can work in equipment built for people. The price is that standing still uses power (about 188 W for Spot) Our calculation
- Research on learned walking is advancing. Even so, scenes where sensors cannot see real terrain correctly remain a challenge Sourced
- The job of an inspection robot is to collect data and hand it to people for decisions. The “effect” is a customer remark on a company page, and independent verification could not be confirmed
- Explosion-protection certification has a scope covering the class of place (zone), the gas group and the equipment configuration. ANYmal X is described by the company as “up to Zone 1 IIB” Sourced
- Japan has its own type verification. Foreign test reports can be used in an application under conditions Sourced. For legged robots in explosive areas, both standards and certification are still being built out
10. How to read the yardsticks and standards
The ability of a legged inspection robot is expressed by the terrain it can handle (maximum step and slope), its payload, runtime, sensor range, dust and water protection (IP) and operating temperature. These are values under conditions the maker chose. For explosion protection, certification (ATEX, IECEx) and Japan’s type verification are separate, and the question is whether the scope of certification matches the place of use. The table below shows what we could confirm (checked 25 October 2026).
| What is evaluated | Typical test or benchmark (name, source) | Standard, rule or guidance | Reading notes |
|---|---|---|---|
| Mobility (steps, slopes, speed) | Company’s stated: Spot max step 300 mm, slope +/-30 deg, 1.6 m/s [Ref. 1]; ANYmal normal 0.75 m/s [Ref. 5] Sourced. Research: learned control (Hwangbo 2019, Lee 2020, Miki 2022) [Ref. 14, 15, 16] | Could not be confirmed (no common test standard was found) | Company values lack conditions. Robot, terrain and metrics differ between studies |
| Evaluation by competition | Analysis of the DARPA Subterranean Challenge (2018 to 2021) [Ref. 17] Sourced | – | Results under the competition’s conditions, not field records |
| Runtime and battery | Spot: 564 Wh, average 90 min [Ref. 1]; ANYmal: 90 min, full charge 3 h [Ref. 5] Sourced | Could not be confirmed | Averages that change with conditions. Standing still also uses power |
| Dust and water protection | Spot IP54; ANYmal and ANYmal X IP67 [Ref. 1, 5, 6] Sourced | Could not be confirmed (we did not check the standard number for IP classes) | Company’s stated. Who ran the tests could not be confirmed |
| Explosion protection (EU) | ANYmal X “ATEX and IECEx certified up to Zone 1 IIB” (company’s statement) [Ref. 6] Sourced | Directive 2014/34/EU (equipment categories) [Ref. 8]; Directive 1999/92/EC (zones) [Ref. 7] Sourced | The certificate was not checked. Check the scope (place, gas, temperature class, configuration) |
| Explosion protection (international) | IECEx certificates and test reports (ExTR) [Ref. 9] Sourced | The IEC 60079 series (-0 general requirements, -1 flameproof, -11 intrinsic safety and others) [Ref. 10] Sourced | The texts are paid. Requirements are not stated here |
| Explosion protection (Japan) | Type verification; conditions for using ExTRs and similar as application documents [Ref. 11] Sourced | Art. 44-2 of the Industrial Safety and Health Act (type verification by a registered body) [Ref. 11] Sourced | Treatment of mobile robots unconfirmed. The circular is dated 5 March 2020 |
| Robot safety | Spot: designed according to ISO 12100 and IEC 60204-1 (specification sheet) [Ref. 1] Sourced | ISO/CD 25785-1 (in development, 30.60) [Ref. 12] Not yet confirmed; ISO 12100 [Ref. 13] | “The method used in design” is not conformity of the whole product |
| Effect of deployment | A customer remark (uptime up 1.5%, ANYbotics page) [Ref. 5] Sourced | – | Conditions, period and independent verification could not be confirmed |
The arrangement of the table is our own Our calculation (arrangement). Numbers, titles and stages of standards and directives were checked on ISO pages, EUR-Lex and IECEx pages (25 October 2026). The standard texts are paid and were not checked.
Reading notes (for materials engineers)
- A catalogue and a work site are different things: maximum step height and speed are values under test conditions. Performance on wet gratings, icy stairs and dusty places has to be checked separately
- A maker’s stated value and a third party’s verification are different: the numbers and certifications in this article are all company statements, not third-party measurements or a check of certificates
- Whether a standard is a recommendation or a requirement differs: explosion protection can be required by law, and some robot safety standards are still drafts
- Separate plans from results: specifications “coming soon” and draft standards are not settled
- Check the scope of certification: a certificate covers zone, gas group, temperature class and configuration
11. Glossary
- Legged robot
- A robot that walks (or runs) on legs: four-legged, two-legged and so on.
- Inspection robot
- A robot that patrols equipment and collects data with sensors.
- Payload
- The equipment or load that can be fitted to the robot and carried.
- Dock
- A station to which the robot returns automatically to charge.
- Mission
- One round of work, with the route and inspection points set.
- IP54 / IP67
- Protection classes against dust and water. A larger number means stronger protection (we did not check the definitions).
- Explosion protection
- Making sure equipment does not become the ignition source where flammable gas or dust is present.
- Zone (0, 1, 2)
- A class of place by how often an explosive atmosphere such as gas occurs.
- Category (1, 2, 3)
- A class of equipment by its level of protection, in the EU directive.
- ATEX
- The common name for the EU explosion-protection directives (2014/34/EU and 1999/92/EC).
- IECEx
- The IEC’s certification system for equipment for use in explosive atmospheres.
- ExCB / ExTR
- An IECEx certification body / an IECEx test report.
- IEC 60079
- A series of standards for equipment and installations in explosive atmospheres.
- Flameproof enclosure (d)
- A method that protects with a sturdy enclosure so that an explosion does not send flame outside.
- Intrinsic safety (i)
- A method that keeps circuit energy so low that it cannot ignite anything by spark or heat.
- Type verification
- In Japan, verification of an equipment type by a registered body (Industrial Safety and Health Act).
- Zero-shot
- Using on the real robot what was learned in simulation, without further tuning.
- Proprioception
- Information from sensors inside the body, such as joint angles and forces (this article’s description).
- Exteroception
- Information from sensors that see the surroundings, such as cameras and LiDAR (this article’s description).
- DARPA Subterranean Challenge
- A 2018 to 2021 robotics competition for underground environments.
- ISO 25785-1
- A safety standard (in development) for industrial mobile robots such as legged ones.
12. References (primary sources)
- Boston Dynamics “Spot” specification sheet (PDF; updated 22 May 2024; weight, payload, speed, step height, battery, IP rating, standards used in design) — bostondynamics.com/wp-content/uploads/2020/10/spot-specifications.pdf
- Boston Dynamics “Spot – The Agile Mobile Robot” (product page; checked 25 October 2026) — bostondynamics.com/products/spot/
- Boston Dynamics “Industrial Inspection Solutions” (inspection uses: perimeter, thermal, visual, acoustic; checked 25 October 2026) — bostondynamics.com/solutions/inspection/
- Boston Dynamics The company site’s search results page for “ATEX” (0 results; checked 25 October 2026) — bostondynamics.com/?s=ATEX
- ANYbotics “ANYmal – Autonomous Robotic Inspection Solution” (product page; IP67, sensors, battery, walking speed, customer remark; checked 25 October 2026) — anybotics.com/robotics/anymal/
- ANYbotics “ANYmal X – Ex-proof inspection robot” (product page; the company’s statement “ATEX and IECEx certified up to Zone 1 IIB”; IP67; thermal camera; 2026 specifications “coming soon”; checked 25 October 2026) — anybotics.com/robotics/anymal-x/
- European Union Directive 1999/92/EC (minimum requirements for improving the safety and health protection of workers potentially at risk from explosive atmospheres), Annex I “Classification of places where explosive atmospheres may occur” — eur-lex.europa.eu/legal-content/EN/TXT/HTML/?uri=CELEX:31999L0092
- European Union Directive 2014/34/EU (equipment and protective systems intended for use in potentially explosive atmospheres), Article 1 (scope) and Annex I (equipment categories) — eur-lex.europa.eu/legal-content/EN/TXT/HTML/?uri=CELEX:32014L0034
- IECEx “IECEx” (introduction to the IEC system for certification to standards for equipment for use in explosive atmospheres; established 1996) — iecex.com/
- IECEx “Standards” (list of standards used by IECEx; titles of the IEC 60079 series) — iecex.com/certified-equipment-scheme/standards/
- MHLW (Japan) MHLW circular “Procedures for applying for type verification of explosion-protected electrical equipment”, Kian-hatsu 0305 No. 1, 5 March 2020 (as posted by the Japan Advanced Information Center of Safety and Health; in Japanese) — jaish.gr.jp/anzen/hor/hombun/hor1-61/hor1-61-4-1-0.htm
- ISO “ISO/CD 25785-1 Robotics — Safety requirements for dynamically stable industrial mobile robots (legged, wheeled, or other forms of locomotion) — Part 1: Robots” (ISO page; stage 30.60; checked 25 October 2026) — iso.org/standard/91469.html
- ISO “ISO 12100:2010 Safety of machinery — General principles for design — Risk assessment and risk reduction” (ISO page) — iso.org/standard/51528.html
- Hwangbo J. et al. “Learning agile and dynamic motor skills for legged robots”, Science Robotics 4(26), 2019, DOI 10.1126/scirobotics.aau5872 — doi.org/10.1126/scirobotics.aau5872
- Lee J. et al. “Learning quadrupedal locomotion over challenging terrain”, Science Robotics 5(47), 2020, DOI 10.1126/scirobotics.abc5986 — doi.org/10.1126/scirobotics.abc5986
- Miki T. et al. “Learning robust perceptive locomotion for quadrupedal robots in the wild”, Science Robotics 7(62), 2022, DOI 10.1126/scirobotics.abk2822 — doi.org/10.1126/scirobotics.abk2822
- Chung T. H. et al. “Into the Robotic Depths: Analysis and Insights from the DARPA Subterranean Challenge”, Annu. Rev. Control Robot. Auton. Syst. 6, 477-502 (2023), DOI 10.1146/annurev-control-062722-100728 — doi.org/10.1146/annurev-control-062722-100728
- Hutter M. et al. “ANYmal – a highly mobile and dynamic quadrupedal robot”, Proc. 2016 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), pp. 38-44, DOI 10.1109/IROS.2016.7758092 — doi.org/10.1109/IROS.2016.7758092
13. Claim-to-source audit
| Claim in the text | Basis | Type |
|---|---|---|
| Spot specification sheet (updated 22 May 2024): weight 32.7 kg, dimensions, payload 14 kg, max speed 1.6 m/s, max slope +/-30 deg, max step 300 mm, battery 564 Wh with 90 min average run, 180 min standby and 60 min recharge, IP54, -20 to 55 C (power on at 0 C or above), designed according to ISO 12100 and IEC 60204-1, emergency stop meets ISO 13850 | Maker specification sheet (company’s stated values) Reference 1 https://bostondynamics.com/wp-content/uploads/2020/10/spot-specifications.pdf | Sourced |
| Spot product page: uses (industrial inspection, power, oil and gas and so on), both remote and autonomous operation, missions launched from the dock | Maker product page Reference 2 https://bostondynamics.com/products/spot/ | Sourced |
| Boston Dynamics inspection uses: perimeter, thermal, visual, acoustic | Maker page Reference 3 https://bostondynamics.com/solutions/inspection/ | Sourced |
| The search for “ATEX” on the Boston Dynamics site returned 0 results (25 October 2026) | The company site search results page Reference 4 https://bostondynamics.com/?s=ATEX | Sourced |
| ANYmal: IP67, standard payload (20x visual zoom, thermal -40 to 550 C, ultrasonic microphone 0 to 384 kHz, light, LiDAR), extra payload 10 kg, walking speed 0.75 m/s, battery 90 min, 70% quick charge in 100 min, full charge 3 h, walking range about 2 km (90 to 120 min), open grated stairs and so on, and a customer remark (1.5% higher uptime) | Maker product page (company’s stated values; a customer remark on the company page) Reference 5 https://www.anybotics.com/robotics/anymal/ | Sourced |
| ANYmal X: “ATEX and IECEx certified up to Zone 1 IIB” (the company’s statement), IP67, thermal camera -10 to +400 C, offshore record (the company’s statement), 2026 specifications coming soon | Maker product page (company’s statements) Reference 6 https://www.anybotics.com/robotics/anymal-x/ | SourcedNot yet confirmed |
| Directive 1999/92/EC Annex I: definitions of zones 0, 1, 2 (gas, vapour, mist) and zones 20, 21, 22 (dust) | Directive text on EUR-Lex Reference 7 https://eur-lex.europa.eu/legal-content/EN/TXT/HTML/?uri=CELEX:31999L0092 | Sourced |
| Directive 2014/34/EU: definitions of equipment categories 1, 2, 3 (Annex I) and the exclusion of seagoing vessels and mobile offshore units (Article 1) | Directive text on EUR-Lex Reference 8 https://eur-lex.europa.eu/legal-content/EN/TXT/HTML/?uri=CELEX:32014L0034 | Sourced |
| IECEx was established by the IEC in 1996; certification bodies (ExCBs); titles in the IEC 60079 series (-0, -1, -2, -7, -11, -15, -18, IEC/TS 60079-32-1 and others) | IECEx pages Reference 9 https://www.iecex.com/ Reference 10 https://www.iecex.com/certified-equipment-scheme/standards/ | Sourced |
| Type verification of explosion-protected electrical equipment (Art. 44-2(1) of the Industrial Safety and Health Act), use of ExTRs and ATEX test reports meeting four conditions, Kian-hatsu 0305 No. 1 (5 March 2020) | MHLW circular (as posted by JAISH) Reference 11 https://www.jaish.gr.jp/anzen/hor/hombun/hor1-61/hor1-61-4-1-0.htm | Sourced |
| Scope of ISO/CD 25785-1 (industrial environments; explosive atmospheres not covered as hazards), stage 30.60, under development | ISO page (checked 25 October 2026) Reference 12 https://www.iso.org/standard/91469.html | SourcedNot yet confirmed |
| ISO 12100 is the basic standard on risk assessment and risk reduction | ISO page Reference 13 https://www.iso.org/standard/51528.html | Sourced |
| Research on learning-based control: simulation-trained control (Hwangbo 2019), challenging natural terrain (Lee 2020), sensing challenges and an hour-long Alpine hike (Miki 2022) | Paper abstracts (via Crossref) Reference 14 https://doi.org/10.1126/scirobotics.aau5872 Reference 15 https://doi.org/10.1126/scirobotics.abc5986 Reference 16 https://doi.org/10.1126/scirobotics.abk2822 | Sourced |
| A review of the results and lessons of the DARPA Subterranean Challenge (2018 to 2021) | Review abstract (via Crossref) Reference 17 https://doi.org/10.1146/annurev-control-062722-100728 | Sourced |
| Title and bibliography of the 2016 IROS paper introducing ANYmal | Paper bibliography (via Crossref) Reference 18 https://doi.org/10.1109/IROS.2016.7758092 | Sourced |
| Spot’s average power of 376 W (564 / 1.5) and standby 188 W (564 / 3); ANYmal’s average speeds of 0.37 and 0.28 m/s | Our calculation (division of stated values; not measured) | Our calculation |
| ANYmal X certificates, bodies, temperature class and dust applicability; ANYmal weight; official statements on Spot explosion protection; treatment of legged robots in Japan’s type verification; independent verification of deployment effects | Could not be confirmed in the scope of this research, so not stated (this article) | Commentary |
| The readings that legs choose footholds, why standing uses power, the three conditions for explosion, the pairing of zones and categories, how to read “Zone 1 IIB”, and the materials views | Our commentary based on the published content; not a view stated by any of the bodies | Commentary |
| Figures 2 to 5 and 7 to 9 are explanatory drawings, not observations of real data; Figures 1 and 6 are frames for AI-generated images | Note in this article | Commentary |
Last updated: 25 October 2026 / Sources are limited to companies’ official pages and specification sheets, EU directives, IECEx pages, a circular of Japan’s Ministry of Health, Labour and Welfare, official ISO pages and papers. Performance values and certifications are companies’ stated values and statements; the certificates themselves were not checked. The certificates and scope of ANYmal X, the weight of ANYmal, an official statement on explosion protection for Spot, the treatment of legged robots in Japan’s type verification, and independent verification of deployment effects could not be confirmed and are not stated. The figures are explanatory concept drawings or drawings that include our calculation; Figures 1 and 6 are ImageGen-generated conceptual illustrations.