TECHNOLOGY EXPLAINER
Agricultural and Construction Robots
― Machines working in fields and on building sites, and what could be confirmed about the companies behind them
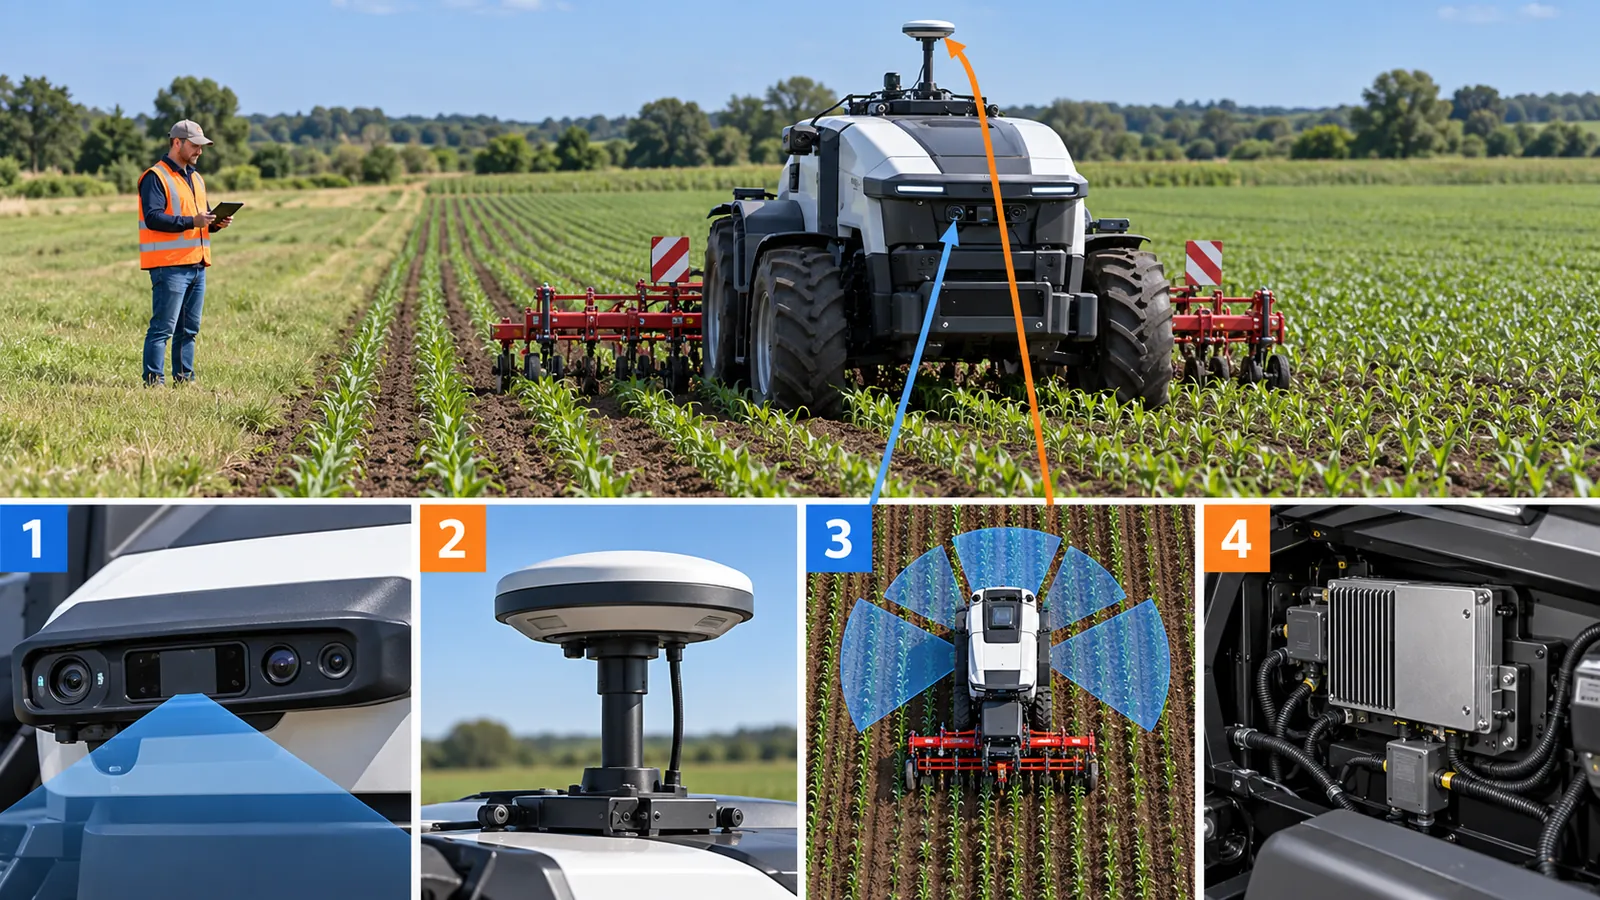
A tractor with nobody on board tills a field. A camera finds only the weeds and sprays herbicide just there. A robot prints design lines on a floor. On a dam project, several construction machines move according to a plan sent by a person. Farming and construction share one trait: they are outdoor work against soil and weather, and both are described as short of labor. This article assumes no robotics background. It covers (1) the stages of driverless tractors, (2) weeding and spraying robots, (3) harvesting robots, (4) layout marking and earthwork automation in construction, (5) materials problems of outdoor machines, and (6) the companies involved (John Deere, Kubota, Carbon Robotics, Built Robotics, Dusty Robotics, Boston Dynamics and Kajima Corporation), using diagrams and small calculations.
Companies’ statements about deployment, units and effects are all written as company claims, and those backed by independent studies are separated. No market-research estimates are used. It separates what could be confirmed, what is a company claim, what is a plan, and what could not be confirmed.
- The short version / what to know first / where this fits in the series
- Agriculture and construction: what they share and where they differ
- Driverless tractors: “unmanned” has stages
- Weeding and spraying robots: the benefit and the cost of targeting
- Harvesting robots: still a hard job
- Construction robots 1: surveying, layout marking and inspection
- Construction robots 2: automating excavation and earthwork
- Materials problems of outdoor machines
- The companies: what could be confirmed
- Where things stand (checked 25 October 2026)
- How to read the yardsticks and standards
- Glossary / References / Claim-to-source audit
Sourced = stated in a published source (link given)
Our calculation = a value we calculated from stated assumptions
Not yet confirmed = a plan, a target, or research with no confirmed track record
Structural summaries and materials-related readings are marked as “explanation”. Inference is shown in bold. Every analogy comes with its limits.
Each company’s “units deployed”, “work rate”, “savings rate” and “accuracy” are statements on its official site or announcement and are not necessarily independently verified. Where an independent paper exists, it is noted. Figures of different companies and models are not lined up to rank them. Company revenue, valuations and share prices are not discussed. This field changes quickly, so model names, rules and planned launches carry a check date (25 October 2026). Planned launches and targets are “not yet confirmed”, not achieved facts. Military and attack equipment is not covered.
1. The short version / what to know first / where this fits in the series
- “Unmanned” farming has stages. The MAFF guideline in Japan organizes automated farm machinery into manual operation, auto-steering with the operator on board, automated driving under visual supervision, and automated driving under remote monitoring Sourced[Ref. 1]. Kubota announced that it plans to launch, in April 2027 in Japan, an unmanned tractor used under remote monitoring (a plan) Sourced[Ref. 3] Not yet confirmed.
- Targeted spraying saves money, but escapes have a price. Cameras find weeds and spray only where needed. A three-year Arkansas trial reduced the sprayed area by 20-90% and saved cost, but weeds increased when the sensitivity was set low Sourced[Ref. 6].
- Harvesting robots are still hard. A 2014 review reported averages over 50 robots of a 66% harvest success rate and 33 s per cycle, and none was commercialized Sourced[Ref. 10]. In construction, layout marking (drawing lines on a floor) and automated operation of construction machines on dam projects appear in official materials, but the effects are mostly company claims.
No prior knowledge is needed. Think of a robot as three things combined: sensing (sensors), thinking (control and intelligence), and moving (actuators). For a weeding robot, cameras “sense”, a processor “thinks” whether something is a weed, and nozzles or lasers “act”. Unlike a factory, fields and building sites change daily in ground, light and weather, so “sensing” and “thinking” are harder.
This article covers robots that do work outdoors. For position estimation see our explainer on SLAM and localization; for vision see robot vision and perception; for walking inspection robots see legged and inspection robots; for drones that survey or spray see drone logistics and drone regulation and airspace management; and for the way safety standards are read see how to read robot safety standards.
2. Agriculture and construction: what they share and where they differ
Both are outdoor work on soil with large machines. In its Form 10-K Deere names, among customers’ challenges, labor shortages, volatile input costs and executing jobs in tighter timeframes Sourced[Ref. 4]. MLIT, noting that further population decline is expected and that infrastructure must still be built and maintained, is promoting labor saving on construction sites Sourced[Ref. 17]. Kubota cites an aging farming population and farmers leaving the industry Sourced[Ref. 3].
What they share is that position is fixed with satellite positioning (GNSS) plus a correction (RTK). Kubota’s tractor and Built Robotics’ excavator kit both use GNSS and RTK, according to their descriptions Sourced[Ref. 3, 13]. The difference lies in what the machine works on. In farming it is crops and weeds, living things that differ one by one in shape and growth. In construction it is a shape fixed by numbers in a design model (BIM), and soil, steel and concrete (explanation). Farming is mainly hard because of telling what is there; construction because of placing things exactly where the drawing says.
3. Driverless tractors: “unmanned” has stages
“Unmanned tractor” sounds as if no person is needed. But Japan’s MAFF “Guideline for Ensuring Safety of Automated Agricultural Machinery” (set in March 2017, last revised in March 2026) lays out stages Sourced[Ref. 1, 2].
- Manual operation: a person does all driving and work. Remote-control mowers also fall in this earlier category, outside the guideline’s scope.
- Auto-steering with the operator on board: the person stays on the machine and the machine assists with steering and similar tasks.
- Automated driving under visual supervision: the machine runs unmanned, and the person watches from a place where it can be seen (in or around the field), judges danger and responds to faults.
- Automated driving under remote monitoring: the machine runs unmanned and the person watches remotely, for example on a monitor. When a fault occurs, the person grasps the surroundings on the monitor and takes appropriate action.
The March 2026 revision added the combine harvester to the machines used under remote monitoring, which now covers robot tractors, tea-garden robots and robot combines. Automated driving between fields is described as under development Sourced[Ref. 1].
Kubota’s example: an unmanned tractor under remote monitoring (planned April 2027)
On 6 August 2026 Kubota announced that it plans to launch the Agri Robo Tractor MR series (unmanned and manned models) in Japan in April 2027. The unmanned model detects people with five AI cameras and obstacles with five millimetre-wave radars, and stops immediately when it detects either. Position is set with GNSS and RTK correction, and on first use a person drives once around the field perimeter so that the machine learns its shape and then plans an efficient route. On a tablet the user can check the surroundings and, after a fault, send a restart command remotely. Kubota says these are the first domestically manufactured tractors capable of unmanned autonomous operation under remote monitoring (as of 6 August 2026, by its own research). The product is for Japan only, with no plans for sale outside it Sourced[Ref. 3]. The launch is a plan and not confirmed Not yet confirmed.
This is inaccurate. The stages in the MAFF guideline distinguish where and how the person watches. Under both visual supervision and remote monitoring, the user monitors the machine and its surroundings, judges danger and responds to faults [Ref. 1]. Even with remote monitoring, it asks that an emergency system be prepared beforehand, such as having someone who can rush to the site [Ref. 1]. Unmanned operation reduces “time sitting in the cab”, but responsibility and monitoring do not disappear (explanation).
Where Deere stands (from its 10-K)
Deere & Company (John Deere) makes agricultural, turf, construction and forestry machines. Its 10-K divides the business into Production & Precision Agriculture (large tractors, combines and others), Small Agriculture & Turf, Construction & Forestry and financial services; lists automation, autonomy and digitalization among its long-term ambitions (Leap Ambitions); and says it is developing autonomous solutions in small agriculture Sourced[Ref. 4]. The specifications and unit counts of individual autonomous products could not be confirmed in the official materials this article could open.
4. Weeding and spraying robots: the benefit and the cost of targeting
Treating weeds only where they are found, rather than spraying the whole field, is now a practical method.
Targeted spraying: John Deere’s See & Spray
See & Spray, which began in 2021, uses cameras and processors on the sprayer boom to scan 2,500 square feet (about 232 m2) per second (at up to 15 mph), finds weeds and opens and closes individual nozzles Sourced[Ref. 5]. Dividing 2,500 square feet per second by 15 mph (about 6.7 m/s) gives a width of about 35 m (about 114 ft) Our calculation. Deere says that in 2025 it was used on more than five million acres, cut non-residual herbicide use by nearly 50% on average and saved about 31 million gallons of spray mix (a company claim) Sourced[Ref. 5]. Dividing the savings by the area gives about 6.2 gallons per acre (31,000,000 / 5,000,000) Our calculation. The same announcement also says third-party trials found an average soybean yield increase of 2 bu/A (up to 4.8 bu/A) (company claim).
An independent trial: the trade-off between savings and escapes
Avent et al. (2026) of the University of Arkansas compared, over three years in Arkansas soybean, broadcast spraying with See & Spray targeted spraying (at high and low sensitivity). The sprayed area fell to 20-90% of broadcast. In early spraying the share was 57.9% at high and 41.3% at low sensitivity; in mid-season it was 49.3% at high and 48.1% at low sensitivity. Against a broadcast post-emergence cost of US$227.22/ha, targeted spraying saved US$43.22-129.19/ha, which is 19% to 57% Sourced[Ref. 6] Our calculation.
But when the low sensitivity was used for three years, weed (Palmer amaranth) density rose from 867 plants/ha to 2,870 and then 11,300 plants/ha (about 13 times). The paper says this was likely due to more escaped weeds at harvest. At high sensitivity and with broadcast spraying, the soil seedbank did not increase over the three years Sourced[Ref. 6].
This holds under conditions. In the independent three-year trial, a high-sensitivity setting kept the seedbank from growing and saved cost, while a low-sensitivity setting let missed weeds increase [Ref. 6]. Look not just at “how many percent less” but at which setting, how many years, and what happened to escapes. The result is also for one site, soybean and a particular herbicide program, and may not apply to other crops or regions (the paper’s scope).
Laser weeding: Carbon Robotics’ LaserWeeder
Some machines burn weeds with lasers instead of herbicide. For the first LaserWeeder, introduced in February 2022, Carbon Robotics states a 20 ft width, a weight of 9,500 lb (about 4,309 kg), thirty 150 W diode lasers, 42 high-resolution cameras, more than 5,000 weeds per minute and removal of up to 99% of weeds (company claims; figures are from the first-generation specification page) Sourced[Ref. 7]. The product carries a “Class 4 laser product” warning (direct or scattered light can harm eyes and skin) Sourced[Ref. 7]. The company says it was founded in 2018, is headquartered in Seattle and has customers in 15 countries Sourced[Ref. 8].
As independent work, a 2025 review in Weed Research presents laser weeding as a sustainable alternative that combines deep-learning identification of weeds and crops with laser removal, and says there are adoption barriers Sourced[Ref. 9]. The company’s own figures (“zero herbicide”, “5-50% yield increase” and so on, on its site) are company claims, and no independent verification could be confirmed here.
5. Harvesting robots: still a hard job
Harvesting means finding a soft fruit hidden among branches and leaves, and detaching it without damage. It is easy for human hands and hard for robots, for four reasons: (1) finding it (hidden by leaves, changing light), (2) reaching it (avoiding branches and leaves), (3) detaching it (cutting or pulling the stalk), and (4) not damaging it.
The review by Bac et al. (2014) summarized averages for 50 harvesting robots for high-value crops: 85% localization success, 75% detachment, 66% harvest, 5% fruit damage, 45% peduncle damage, and a cycle time of 33 s (shortest: 1 s for a kiwi robot). It added that performance had not improved in three decades and that none of the 50 robots was commercialized (as of 2014) Sourced[Ref. 10]. A robot with 66% success and 33 s cycles, running for an hour, makes 3,600 / 33 = about 109 attempts and, times 0.66, about 72 fruits Our calculation (an illustration built from averages of 50 robots, not the performance of one).
A 2026 review names localization errors, perception-to-action latency and environmental variability as challenges in integrating perception, manipulation and detachment, and says moving from experimental systems to commercially viable ones requires performance metrics, economics and scaling Sourced[Ref. 11].
To match human work, a robot must meet speed, success rate and low damage at the same time. Trying again and again to raise the success rate takes time and also bruises fruit. The numbers here are averages from a 2014 review, and recent machines may do better. As far as could be confirmed, recent reviews still list challenges for field deployment (explanation).
6. Construction robots 1: surveying, layout marking and inspection
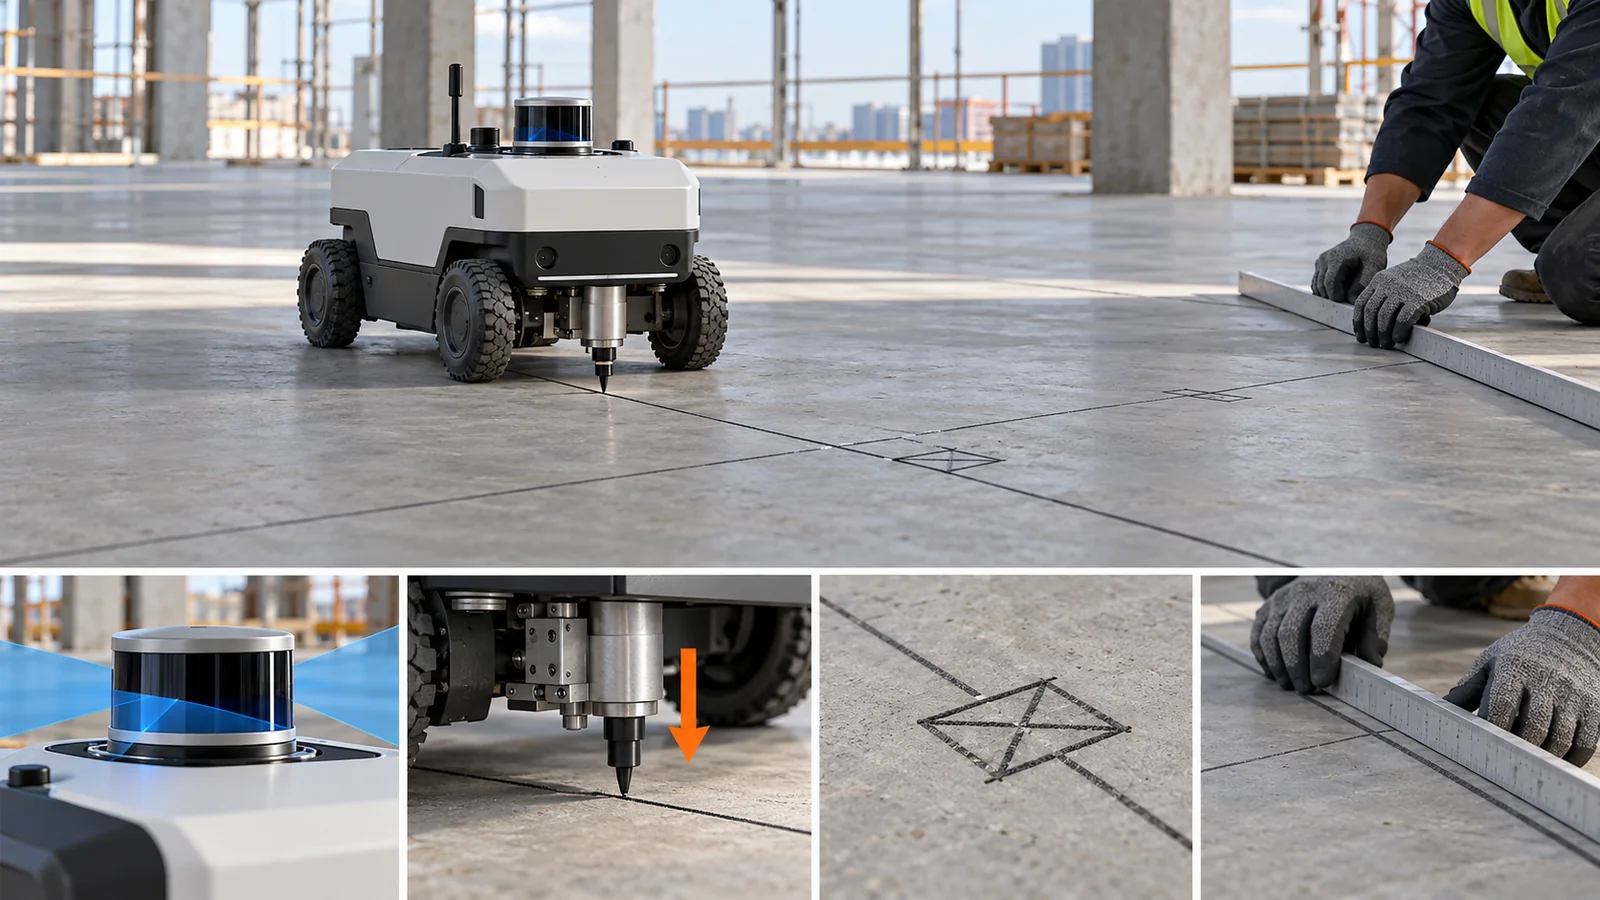
On a construction site, positions in the design must be transferred to floors and walls: layout marking. Today people mark one point at a time with tape and lasers, and robots that do this have appeared.
Dusty Robotics: printing design lines on the floor
Dusty Robotics provides the “FieldPrinter”, a robot that automatically prints lines and symbols on the floor based on BIM (a 3D building model). The company says one person can lay out 10,000-15,000 square feet a day (about 929-1,394 m2) Our calculation, with accuracy up to 1/16 inch (about 1.6 mm), and that it can print several trades’ layouts at once (company claims). The FieldPrinter is available in North America Sourced[Ref. 12].
Boston Dynamics’ Spot: patrolling and recording the site
Boston Dynamics describes uses of its Spot robot on construction sites: autonomous patrols capturing 360-degree images and video to record progress, and laser scanning to gather 3D data that feeds BIM and digital-twin systems Sourced[Ref. 14]. It states a 14 kg payload and more than 1,500 robots in customers’ hands (company claims) Sourced[Ref. 15]. The structure of legged robots is covered in our explainer on legged and inspection robots.
7. Construction robots 2: automating excavation and earthwork
There are also attempts to automate digging, hauling and compacting soil. Here too, remote control and automation differ. Remote control keeps people away from dangerous places, but one person still runs one machine, so labor is not reduced. Automation means you send a plan and the machines move on their own, aiming to run many machines with few people.
Kajima’s A4CSEL: automated operation on dam projects
Kajima Corporation’s A4CSEL is a construction system in which a person sends a work plan to several automated construction machines, which then run unmanned. The company says this differs from conventional remote control by radio. Applications listed are the Naruse Dam body-placement works (works May 2018 to December 2026), the Koishiwaragawa Dam (completed March 2021), the Oitagawa Dam (completed November 2019) and the Gokayama Dam (completed March 2018) (the company’s description) Sourced[Ref. 16]. The machines involved include vibratory rollers, bulldozers and dump trucks.
Built Robotics: retrofitting autonomy to existing excavators
Built Robotics’ Exosystem is a kit fitted to existing excavators so they can operate autonomously. It includes an all-weather enclosure, 360-degree smart cameras, GPS and a liquid-cooled computer, and is managed from a cloud command centre called Everest. For precision it uses RTK GPS, IMUs and laser rangefinders (company description). Its current focus is piling for solar power plants (the RPD 35 and RPS 25), and it advertises operation up to 24 hours a day and an eight-layer safety system Sourced[Ref. 13].
National policy: i-Construction 2.0
On 16 April 2024 MLIT formulated “i-Construction 2.0”. It aims to cut labor on construction sites by at least 30%, that is raise productivity 1.5 times, by fiscal 2040, with three pillars: automation of construction, of data linkage and of construction management Sourced[Ref. 17]. “30% labor saving” and “1.5 times” roughly match: the same work with 70% of the people is 1 / 0.7 = about 1.43 times Our calculation. This is a target, not an achieved fact Not yet confirmed.
This is inaccurate. Kajima’s listed applications centre on large works such as dam bodies, sites where the place, extent and procedure of work can be decided in advance [Ref. 16]. Whether this can extend to complex, changing sites could not be confirmed in this article’s sources. Companies’ statements (number of deployments, safety, efficiency) have no independent verification that could be confirmed here.
8. Materials problems of outdoor machines
Unlike factory robots, farm and construction robots face soil, rain, dust, temperature and vibration. For a materials engineer, the problems sort out as follows.
Original SVG, detailed explanation and sources
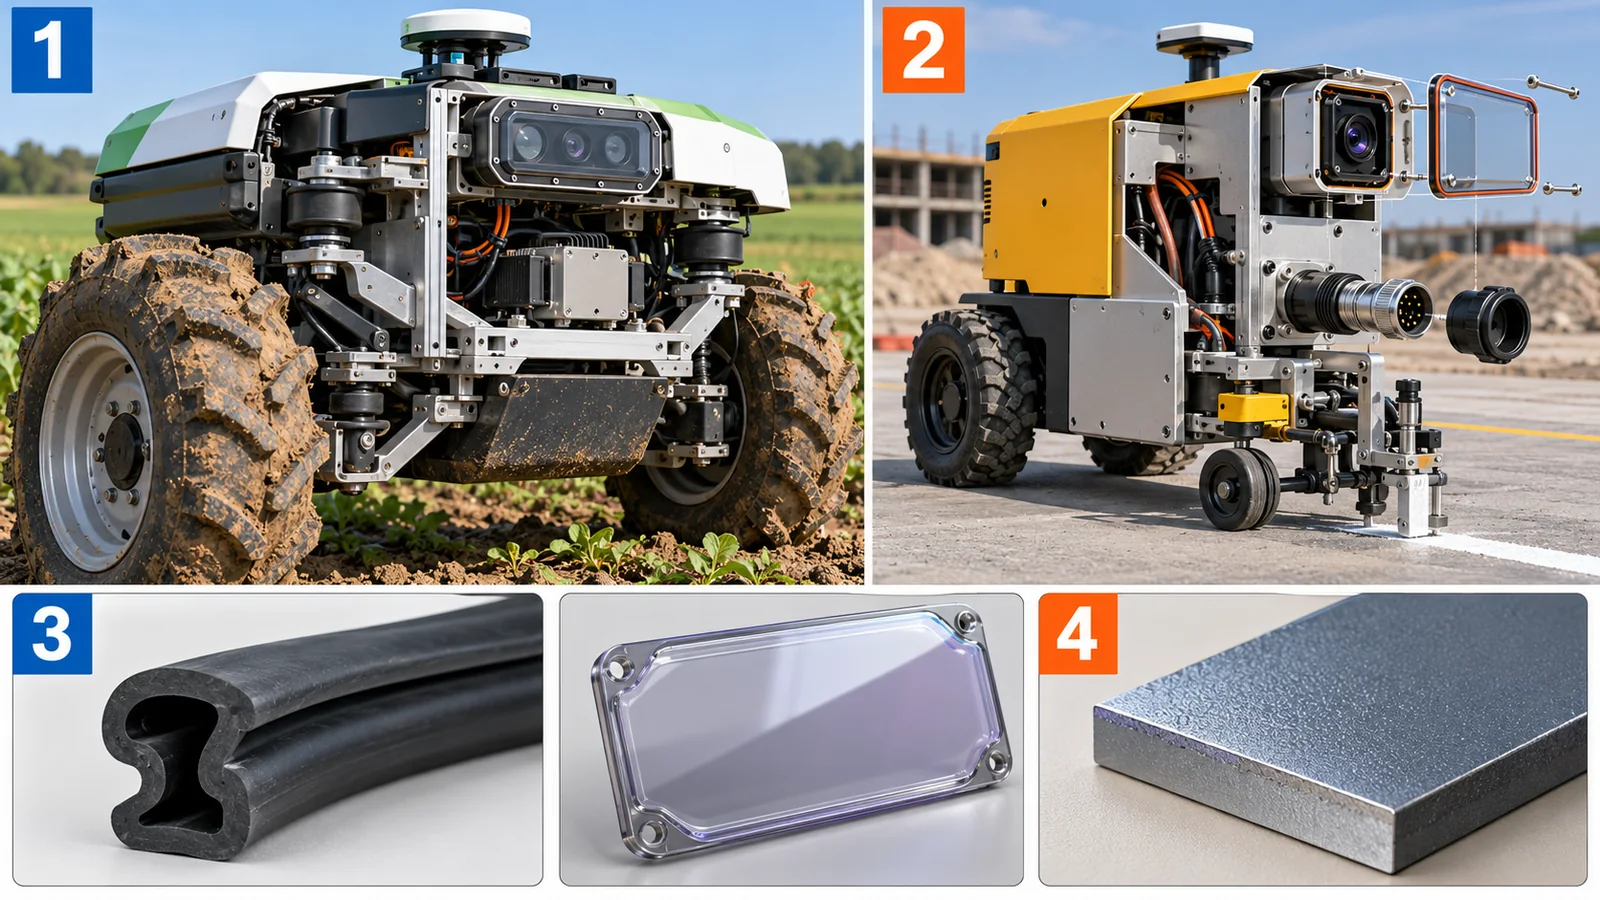
Original SVG reference: Concept diagram (vector drawing). Loads on outdoor robots and materials responses. The vibration column is our explanation, not a sourced fact.
Parts that touch the soil, such as tillage tools, are strongly exposed to abrasive wear (hard sand grains scouring the surface). The review by Malvajerdi (2023) summarizes that the wear rate of tillage tools increases with the size of sand particles in the soil, that coating methods and materials have been studied to resist wear, and that coated tillage tools were reported to need less draft force Sourced[Ref. 19]. From a materials side it is a trade-off among steel hardness, coating hardness and adhesion, and cost. A method that does not touch the soil, such as laser weeding, can also be read as avoiding this wear (inference).
Built Robotics says the Exosystem enclosure is made of steel and aluminum, resists dust and rain, and withstands temperatures from -40 C to 55 C (company description) Sourced[Ref. 13]. Outdoors, sealing and heat dissipation are hard to reconcile, and vibration can fatigue wiring and connectors (our explanation). Laser weeding uses Class 4 lasers, so a housing that keeps light in and clear safety labels become requirements for materials and structure [Ref. 7].
9. The companies: what could be confirmed
Only companies whose business could be confirmed from official materials are described. Company ranking, valuation and share price are not discussed.
| Company | Field / type | What official materials confirm (checked 25 October 2026) | Label / caution |
|---|---|---|---|
| Deere & Company (John Deere) | Large machinery maker (agriculture, construction, forestry) | Four business segments; automation, autonomy and digitalization among its long-term ambitions. See & Spray started in 2021; used on over 5 million acres in 2025, cutting spray mix by nearly 50% on average (company claim) [Ref. 4, 5] | Sourced. The savings rate is a company claim. Independent trial in Chapter 4 (Avent et al.) |
| Kubota Corporation | Large machinery maker (agriculture) | Agri Robo Tractor MR series (unmanned and manned) planned for April 2027 in Japan. Remote monitoring, five AI cameras and five millimetre-wave radars. Japan only [Ref. 3] | Sourced Not yet confirmed. The launch is a plan |
| Carbon Robotics | Specialist start-up (laser weeding, tractor autonomy) | LaserWeeder (first generation February 2022), thirty 150 W diode lasers, 42 cameras (first-generation specification). Class 4 lasers. Founded 2018, Seattle, 15 countries [Ref. 7, 8] | Sourced. Specifications and effects are company claims |
| Built Robotics | Specialist start-up (construction, excavator autonomy) | Exosystem (retrofit autonomy kit for excavators), 360-degree cameras, RTK GPS, IMUs, laser ranging; solar-plant piling (RPD 35, RPS 25) [Ref. 13] | Sourced. Figures are company claims |
| Dusty Robotics | Specialist start-up (construction layout) | FieldPrinter (BIM-based floor printing). 10,000-15,000 sq ft per day with one person, 1/16-inch accuracy (company claims). Available in North America [Ref. 12] | Sourced. Figures are company claims |
| Boston Dynamics | General-purpose robot firm (site patrol on construction) | Spot patrols construction sites, records 360-degree imagery and laser scans. 14 kg payload; over 1,500 robots with customers (company description) [Ref. 14, 15] | Sourced. The unit count is a company claim |
| Kajima Corporation | Construction firm (automating construction) | A4CSEL applications: Naruse, Koishiwaragawa, Oitagawa and Gokayama dams [Ref. 16] | Sourced. Effects are the company’s description |
| Monarch Tractor, Komatsu and others | – | The official site could not be opened, or the business could not be confirmed within this article’s research, so they are not described | Not yet confirmed |
Checked 25 October 2026. Company plans and targets are separate from achieved facts. The table does not rank the companies.
10. Where things stand (checked 25 October 2026)
This field changes quickly, so here is what could be confirmed from primary sources, with check dates.
| Item | What was confirmed | Label |
|---|---|---|
| Rules for automated driving of farm machinery (Japan) | The MAFF guideline was set in March 2017 and last revised in March 2026. Remote monitoring covers tractors, tea-garden robots and combines [Ref. 1] | Sourced |
| Unmanned tractor under remote monitoring (Kubota) | The MR series is planned for April 2027 in Japan, for Japan only [Ref. 3] | Sourced Not yet confirmed |
| Targeted spraying | An independent three-year trial: sprayed area down 20-90%, saving US$43.22-129.19/ha; weeds increased at low sensitivity [Ref. 6]. Deere announced over 5 million acres in 2025 and an average reduction of nearly 50% (company claim) [Ref. 5] | Sourced |
| Laser weeding | Carbon Robotics announced its first model in February 2022 and has customers in 15 countries (company description). An independent review notes adoption barriers [Ref. 7, 8, 9] | Sourced |
| Harvesting robots | A 2014 review found none of 50 robots commercialized. A 2026 review still lists field-deployment challenges [Ref. 10, 11] | Sourced |
| Construction automation | Kajima’s A4CSEL has been applied to dam works (company description). MLIT targets 30% labor saving by FY2040 (a target) [Ref. 16, 17] | Sourced Not yet confirmed |
| Independent verification of construction robots, applicable ISO or IEC numbers, other firms such as Monarch Tractor and Komatsu | Could not be confirmed within this article’s research | Not yet confirmed |
Checked 25 October 2026. Company plans and targets are separate from achieved facts.
Agricultural and construction robots work against outdoor soil and weather and fix position with GNSS and RTK. “Unmanned” in farming has stages (on board, visual supervision, remote monitoring), and responsibility and monitoring remain. Targeted spraying showed savings even in an independent trial, but with the cost that escapes grow if the sensitivity is set low. Harvesting robots struggle to combine success rate and speed. In construction, layout marking and automated operation on large dam works appear in official materials, but effects are mostly company claims. From a materials side, the problems are wear, sealing and temperature, vibration and laser safety.
11. How to read the yardsticks and standards
The quality of agricultural and construction robots cannot be measured by one number. There are several yardsticks: how much labor is saved, speed and accuracy of work, saved inputs (herbicide, fuel), success rate, safety and how long it runs, and their meaning changes with crop, season, soil and site conditions. The table shows what each measures and does not measure, as far as could be confirmed.
| Item | Representative tests / benchmarks (name, source) | Standards, rules, guidance (MAFF, MLIT, ISO and others) | Cautions when reading |
|---|---|---|---|
| Safety of automated driving (farm machinery) | Detection of people and obstacles and automatic stop (Kubota’s description) [Ref. 3] Sourced | MAFF “Guideline for Ensuring Safety of Automated Agricultural Machinery” (set March 2017, last revised March 2026) [Ref. 1, 2] Sourced. ISO 18497:2018 “Agricultural machinery and tractors — Safety of highly automated agricultural machines — Principles for design” (Published, to be revised [90.92]; full text paid and not read) [Ref. 18] Sourced | The guideline is guidance, not law itself. The ISO standard gives design principles; requirements for a specific machine are separate. Its text was not read, so its requirements are not described |
| Effect of weeding and spraying | Sprayed-area share, cost and weed density (Avent et al., an independent three-year trial) [Ref. 6] Sourced | A unified standard could not be confirmed | One site, soybean and a particular herbicide program. Setting (sensitivity) and years can reverse the result |
| Harvesting performance | Success of localization, detachment and harvest, damage and cycle time (Bac et al., a review) [Ref. 10] Sourced | A unified standard could not be confirmed. Bac et al. list “defining requirements and measuring performance” as a challenge | Averages across crops and designs, not the performance of one robot |
| Accuracy of layout and inspection | Dusty: 1/16 inch (company claim) [Ref. 12] Sourced. Spot: 14 kg payload (company description) [Ref. 15] Sourced | Could not be confirmed | The way accuracy was measured (reference, conditions, who measured) is not given. No independent verification was found |
| Achievement of construction automation | Kajima: applications to dam works (company description) [Ref. 16] Sourced | MLIT “i-Construction 2.0”: 30% labor saving and 1.5x productivity by FY2040 (target) [Ref. 17] Sourced Not yet confirmed. No ISO or IEC standard for automated operation of construction machines could be confirmed | A target is not an achievement. Check how counts and reduced headcount are measured |
| Materials and wear | Wear and coating of tillage tools (review by Malvajerdi) [Ref. 19] Sourced | No ASTM International standard or website was consulted. Could not be confirmed here | Wear varies with soil, moisture and sand grains. Do not apply a general trend to a specific machine |
The arrangement of the table is Our calculation (organization). The ISO text is paid and was not read, so only the title and status are given. No ASTM International standard or website was consulted.
Cautions when reading (for materials engineers)
- Demonstrations, benchmarks and the field are different. Moves at a trade show or in promotional video do not show continuous operation in rain, mud, different soils and seasons. Separate an independent trial (Avent et al.) from a company’s announcement.
- Company claims and third-party verification are different. “A nearly 50% average reduction”, “5-50% yield increase” and “5,000 weeds per minute” are statements on companies’ sites and announcements.
- Guidance and requirements are different. The MAFF guideline is guidance, and its legal force was not checked here. The text of ISO 18497 was not read (inference: it is used in explaining product safety).
- Plans and achievements are different. Kubota’s planned launch and the i-Construction 2.0 target are not yet confirmed.
12. Glossary
- Robot agricultural machinery
- Farm machinery with robot technology that drives and works automatically (the Japanese guideline’s term).
- Auto-steering
- A function in which the machine assists with steering, with the person on board.
- Visual supervision / remote monitoring
- Ways of watching an unmanned machine: from a place where it can be seen / on a monitor from a distance.
- GNSS / RTK
- Satellite positioning / a correction method that brings the error down to a few centimetres.
- Millimetre-wave radar
- A sensor that measures the position and motion of objects with radio waves; it works in the dark.
- Field (farm field)
- Land on which crops are grown.
- Targeted (spot) spraying
- Finding weeds and similar targets and spraying only where needed.
- Detection sensitivity
- How hard the system tries not to miss weeds. High means fewer misses but more spraying.
- Escape
- A weed left untreated. It can set seed and increase next year.
- Soil seedbank
- The store of weed seeds remaining in the soil.
- Non-residual herbicide
- A herbicide that does not stay long in the soil after spraying.
- Diode laser
- A semiconductor laser. In weeding it burns the weed’s growing point.
- Class 4 laser
- The highest-hazard class of laser. Even direct or scattered light can harm eyes and skin.
- Cycle time
- The time one task (such as one harvest) takes.
- Peduncle
- The thin stalk joining a fruit to the branch.
- BIM
- Building Information Modeling: a 3D model of a building and the management of its information.
- Layout marking
- Marking positions from the drawings onto the site’s floors and walls.
- Digital twin
- A copy of the state of a real facility inside a computer.
- IMU
- A sensor that measures acceleration and rotation.
- i-Construction
- MLIT’s effort to raise productivity on construction sites; “2.0” aims at labor saving.
- Abrasive wear
- Wear caused by hard grains scouring a surface.
13. References
- Ministry of Agriculture, Forestry and Fisheries (MAFF) Overview of the “Guideline for Ensuring Safety of Automated Agricultural Machinery” (in Japanese; set March 2017, last revised March 2026; checked 25 October 2026) — maff.go.jp/j/kanbo/smart/attach/pdf/index-306.pdf
- Ministry of Agriculture, Forestry and Fisheries (MAFF) “Guideline for Ensuring Safety of Automated Agricultural Machinery” (in Japanese; partially revised March 2026), full text (checked 25 October 2026) — maff.go.jp/j/kanbo/smart/attach/pdf/index-307.pdf
- Kubota Corporation “Kubota to Launch Unmanned Autonomous Tractors with Remote Monitoring Capabilities” (6 August 2026; the company’s announcement; checked 25 October 2026) — kubota.com/news/2026/20260806-001252.html
- Deere & Company Form 10-K (fiscal year ended 2 November 2025, filed 18 December 2025; the company’s own description; checked 25 October 2026) — sec.gov/Archives/edgar/data/315189/000110465925122321/de-20251102x10k.htm
- High Plains Journal “John Deere customers use See & Spray technology across 5 million acres in 2025” (12 November 2025; a reprint of Deere’s announcement of 4 November 2025; checked 25 October 2026) — hpj.com/?p=171146
- Avent T. H. et al. “Weed population impacts using targeted herbicide applications with a precision sprayer in soybean over a three-year period”, Weed Technology 40, e9 (2026) (open-access version read) — doi.org/10.1017/wet.2025.10056
- Carbon Robotics LaserWeeder product page (the company’s description, including the Class 4 laser label; checked 25 October 2026) — carbonrobotics.com/laserweeder
- Carbon Robotics Company page (founded 2018, headquartered in Seattle, customers in 15 countries; the company’s description; checked 25 October 2026) — carbonrobotics.com/about
- Mutuyimana E. et al. “Laser Weeding Technology: A Promising Sustainable Weed Control Method”, Weed Research 65(6), e70037 (2025) — doi.org/10.1111/wre.70037
- Bac C. W. et al. “Harvesting Robots for High-value Crops: State-of-the-art Review and Challenges Ahead”, Journal of Field Robotics 31(6), 888-911 (2014) — doi.org/10.1002/rob.21525
- Ghonimy M., Abdel-Baky M. “Robotic Fruit Harvesting Systems: Integration of Perception, Manipulation, and Detachment for Autonomous Harvesting”, Agronomy 16(12), 1127 (2026) — doi.org/10.3390/agronomy16121127
- Dusty Robotics Dusty Robotics official site (home and about pages; the company’s description; checked 25 October 2026) — dustyrobotics.com/
- Built Robotics Built Robotics technology page (Exosystem; the company’s description; checked 25 October 2026) — builtrobotics.com/technology
- Boston Dynamics Boston Dynamics “Construction” page (the company’s description; checked 25 October 2026) — bostondynamics.com/solutions/construction/
- Boston Dynamics Boston Dynamics “Spot” product page (14 kg payload, more than 1,500 robots with customers; the company’s description; checked 25 October 2026) — bostondynamics.com/products/spot/
- Kajima Corporation A4CSEL technology page (the company’s description, including dam-construction applications; in Japanese; checked 25 October 2026) — kajima.co.jp/tech/civil_engineering/ict/automation/tech032/index.html
- Ministry of Land, Infrastructure, Transport and Tourism (MLIT) Press release “Formulation of i-Construction 2.0” (16 April 2024; in Japanese; checked 25 October 2026) — mlit.go.jp/report/press/kanbo08_hh_001085.html
- ISO ISO 18497:2018 “Agricultural machinery and tractors — Safety of highly automated agricultural machines — Principles for design” (ISO page; status Published, to be revised [90.92]; full text paid and not read; checked 25 October 2026) — iso.org/standard/62659.html
- Malvajerdi A. S. “Wear and coating of tillage tools: A review”, Heliyon 9(6), e16669 (2023) (open version on PMC) — pmc.ncbi.nlm.nih.gov/articles/PMC10279786
14. Claim-to-source audit
| Claim in the text | Basis | Label |
|---|---|---|
| The MAFF guideline’s organization (manual operation, auto-steering with an operator on board, automated driving under visual supervision, automated driving under remote monitoring), the covered robot machines (robot tractor, tea-garden robot, rice transplanter, mower, small utility cart, combine), set March 2017 and last revised March 2026, remote monitoring covering tractors, tea-garden robots and combines, and driving between fields described as under development | MAFF overview document and guideline text Reference 1 https://www.maff.go.jp/j/kanbo/smart/attach/pdf/index-306.pdf Reference 2 https://www.maff.go.jp/j/kanbo/smart/attach/pdf/index-307.pdf | Sourced |
| Kubota plans to launch the Agri Robo Tractor MR series (unmanned and manned) in Japan in April 2027, with a remote-monitoring tablet, five AI cameras and five millimetre-wave radars, GNSS and RTK, conformity with MAFF requirements of March 2024, and no plans to sell outside Japan | Kubota announcement (6 August 2026) Reference 3 https://www.kubota.com/news/2026/20260806-001252.html | Sourced |
| Deere’s segments (production and precision agriculture, small agriculture and turf, construction and forestry), automation, autonomy and digitalization among its long-term ambitions, development of autonomous solutions in small agriculture, and the See & Spray and GUSS brands | Deere’s Form 10-K Reference 4 https://www.sec.gov/Archives/edgar/data/315189/000110465925122321/de-20251102x10k.htm | Sourced |
| See & Spray: launched in 2021, cameras and processors scanning 2,500 square feet per second (up to 15 mph), used on over 5 million acres in 2025, non-residual herbicide use cut by nearly 50% on average (about 31 million gallons), third-party soybean trials averaging 2 bu/A (up to 4.8 bu/A) more yield, and the Application Savings Guarantee (company claims) | Reprint of Deere’s announcement (High Plains Journal) Reference 5 https://hpj.com/?p=171146 | Sourced |
| A three-year Arkansas soybean trial: sprayed-area shares (early 41.3% and 57.9%, mid 48.1% and 49.3%), area reduced by 20-90%, savings of US$43.22-129.19/ha against a broadcast post-emergence cost of US$227.22/ha, no seedbank increase at high sensitivity, and weed density rising 867 to 2,870 to 11,300 plants/ha at low sensitivity | Avent et al. (2026) Reference 6 https://doi.org/10.1017/wet.2025.10056 | Sourced |
| Carbon Robotics LaserWeeder: first-generation specification introduced in February 2022 (20 ft wide, 9,500 lb, thirty 150 W diode lasers, 42 cameras, 5,000+ weeds per minute, up to 99%), a Class 4 laser product, founded 2018, headquartered in Seattle, 15 countries (company description) | Carbon Robotics official pages Reference 7 https://carbonrobotics.com/laserweeder Reference 8 https://carbonrobotics.com/about | Sourced |
| Laser weeding combines deep-learning identification of weeds and crops with laser removal, and has adoption barriers (review) | Abstract of Mutuyimana et al. (2025) Reference 9 https://doi.org/10.1111/wre.70037 | Sourced |
| Averages of harvesting robots (localization 85%, detachment 75%, harvest 66%, fruit damage 5%, peduncle damage 45%, cycle time 33 s, shortest 1 s), no improvement over three decades and none of the 50 commercialized (as of 2014); a 2026 review names localization errors, perception-to-action latency and environmental variability as barriers to field deployment | Abstracts of Bac et al. (2014) and Ghonimy et al. (2026) Reference 10 https://doi.org/10.1002/rob.21525 Reference 11 https://doi.org/10.3390/agronomy16121127 | Sourced |
| Dusty Robotics: BIM-driven layout, 10,000-15,000 square feet per day with one person, up to 1/16-inch accuracy, printing several trades at once, FieldPrinter available in North America (company description) | Dusty Robotics official site Reference 12 https://www.dustyrobotics.com/ | Sourced |
| Built Robotics: the Exosystem (an autonomy kit fitted to existing excavators), 360-degree cameras, RTK GPS, IMUs and laser ranging, a steel-and-aluminum housing rated -40 to 55 C, an eight-layer safety system, and a current focus on solar-plant piling (RPD 35 and RPS 25) (company description) | Built Robotics technology page Reference 13 https://www.builtrobotics.com/technology | Sourced |
| Boston Dynamics’ Spot: autonomous patrol of construction sites capturing 360-degree imagery and laser scans, integration with BIM and digital twins, 14 kg payload, and over 1,500 robots with customers (company description) | Boston Dynamics official pages Reference 14 https://bostondynamics.com/solutions/construction/ Reference 15 https://bostondynamics.com/products/spot/ | Sourced |
| Kajima’s A4CSEL: a next-generation construction system in which a work plan is sent to several automated machines that run unmanned; applications listed include Naruse Dam (works May 2018 to December 2026), Koishiwaragawa Dam (completed March 2021), Oitagawa Dam (completed November 2019) and Gokayama Dam (completed March 2018) (company description) | Kajima technology page Reference 16 https://www.kajima.co.jp/tech/civil_engineering/ict/automation/tech032/index.html | Sourced |
| MLIT’s “i-Construction 2.0” (formulated 16 April 2024): cut labor on construction sites by at least 30% (1.5x productivity) by FY2040, with three pillars (automation of construction, data linkage and construction management); a target and a plan | MLIT press release Reference 17 https://www.mlit.go.jp/report/press/kanbo08_hh_001085.html | Not yet confirmed |
| Title and scope of ISO 18497:2018 (design principles for highly automated agricultural machines) and its status (Published, to be revised); forestry, farm-yard operations and public roads are outside its scope | ISO page Reference 18 https://www.iso.org/standard/62659.html | Sourced |
| Tillage tools wear faster with larger sand grains, and coatings have been studied | Abstract of Malvajerdi (2023) Reference 19 https://pmc.ncbi.nlm.nih.gov/articles/PMC10279786 | Sourced |
| Percentage calculations (43.22/227.22 = 19%, 129.19/227.22 = 57%, 11,300/867 = 13.0), conversions from square feet to m2 (10,000 x 0.0929 = 929 m2; 15,000 x 0.0929 = 1,394 m2), 1/16 inch = 1.59 mm, 3,600/33 = about 109 attempts and x 0.66 = about 72 fruits, 31,000,000/5,000,000 = 6.2 gallons per acre, and the relation between “30% labor saving” and “1.5x” in i-Construction 2.0 (1/0.7 = 1.43) | Our own calculation (assumptions stated in the text and figures) | Our calculation |
| Other firms such as Monarch Tractor and Komatsu, each firm’s installed units, revenue and valuation, independent verification of construction robots, and applicable ISO or IEC numbers for construction robots could not be confirmed within this article’s research and are not included | The scope of research for this article | Explanation |
| The comparison of agriculture and construction, the reading of stages of automation, the materials-engineer notes (wear, temperature, vibration, laser safety), the analogies and their limits, and the fact that the figures are explanatory drawings or frames | This article’s explanation (our reading of the sourced facts) | Explanation |
Last updated: 25 October 2026. Sources are limited to primary material (documents of MAFF and MLIT, Deere’s Form 10-K, official sites and announcements of each company, papers in Weed Technology, Weed Research, Journal of Field Robotics, Agronomy and Heliyon, and an ISO page). Companies’ figures and announcements are labeled as company claims and kept separate from independent verification. No trade-press articles are used; Deere’s announcement was read through a reprint (High Plains Journal). The worked examples (area shares, unit conversions, multiplying success rates) are our own explanatory calculations and not specifications of any model. No market-research estimates are used. Other firms such as Monarch Tractor and Komatsu, independent verification of construction robots and applicable international standard numbers could not be confirmed and are therefore not given. All figures are explanatory concept diagrams or drawings with our own calculations, except Figs. 1 and 6, which are ImageGen-generated conceptual illustrations. They do not depict real machines, sites or appearances.