COMPANY PROFILE / DRONES AND ROBOTICS
NVIDIA
– A company that supports the "learn, test, run" cycle of robots and self-driving with compute and software
NVIDIA is best known as a giant of AI chips, but this article covers only its robotics and autonomous-driving work. It does not build robots. Instead it provides developers worldwide with computers for training a robot’s brain, simulation for testing it in a virtual world, a small computer (Jetson) that runs it inside the robot, and open AI models (GR00T and Cosmos). Company-wide scale is confirmed in its filings with the U.S. SEC, but robotics revenue is not disclosed as its own item. This article lays out that point too.
- NVIDIA in 30 seconds, and where it sits in drones and robotics
- Logo and naming
- Where the company sits in the field
- Scale (limited to robotics and driving)
- Resources behind robotics and driving, and product status
- Track record so far
- Plans
- What the company seems to be aiming for
- Partnership map
- Technologies, products and services
- Risks the company faces
- Glossary / References / Claim-to-source audit
1. NVIDIA in 30 seconds, and where it sits in drones and robotics
Secondary: Humanoids & physical AIDoes not build robots
Jetson Thor, CosmosSupport train, simulate and run
AlpamayoIn-vehicle compute and an open reasoning model
Cosmos (OpenMDW-1.1)Available on GitHub and Hugging Face
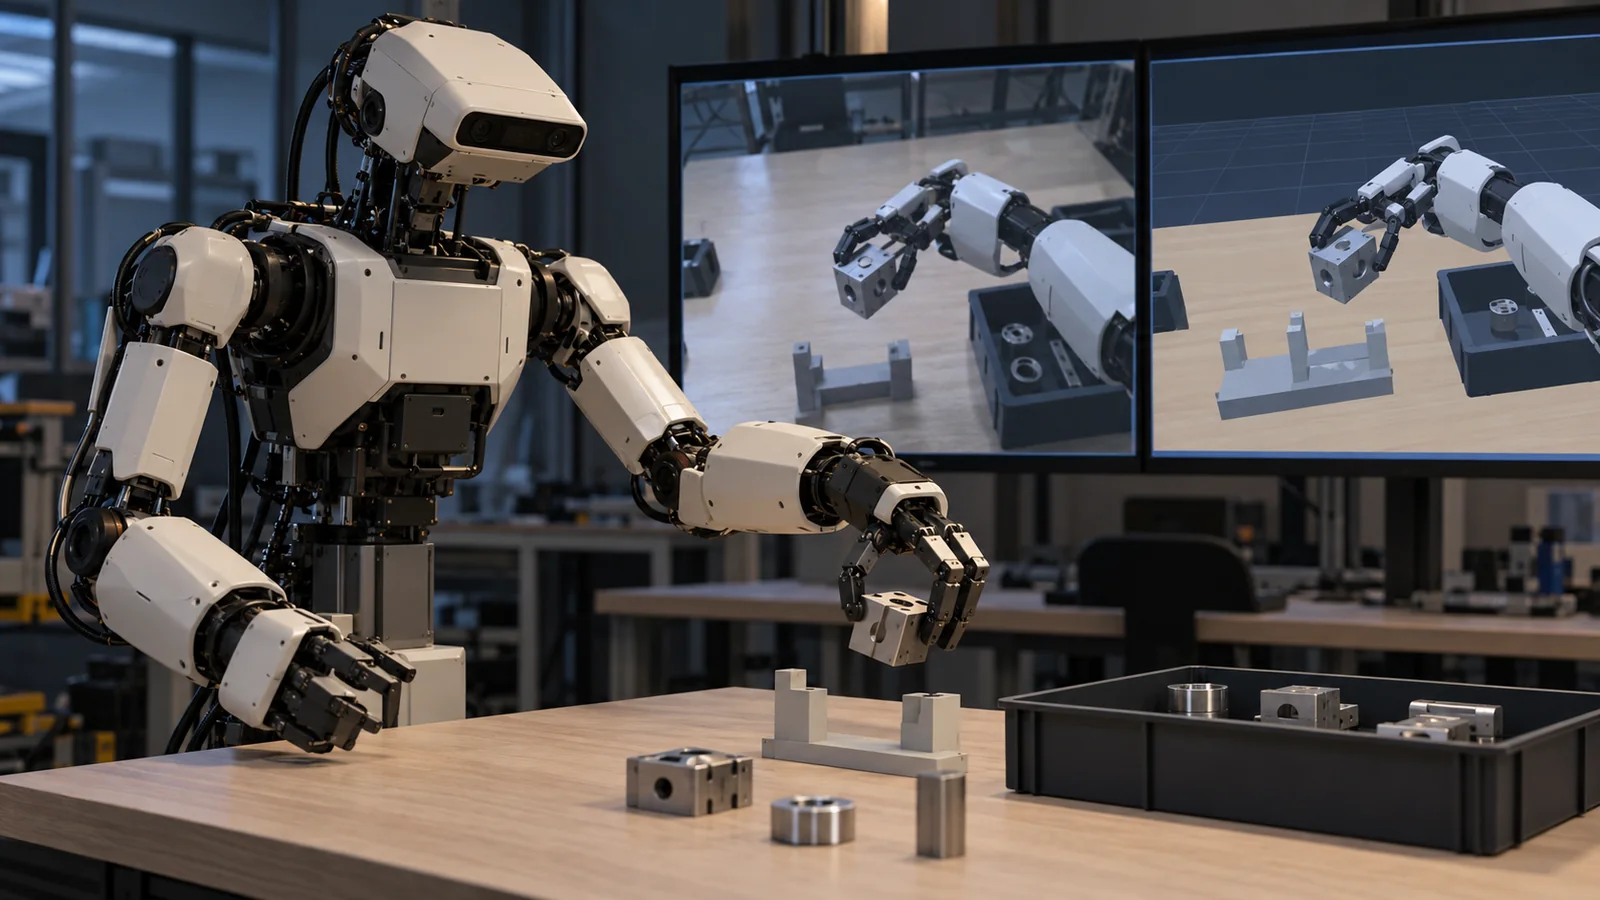
NVIDIA’s role in robotics is supplying "the toolkit for raising a robot’s brain" and "the small computer the brain runs on" Sourced. A robot’s AI is slow and costly to train on real machines alone. So developers try things at scale in a virtual space (simulation), train on the data produced there, and then run the finished model on a computer inside the robot. NVIDIA has products for each of these three stages (see the illustration in Chapter 10). Its 10-K likewise says that for physical AI (AI that works in the real world, such as robots) it provides a platform spanning data-center infrastructure, open models, embedded modules and software for training, simulating and deploying. On the other hand, robotics revenue on its own is not disclosed in the 10-K or 10-Q. We keep facts and the company’s own descriptions apart.
2. Logo and naming
Naming note: the company name is NVIDIA Corporation; this article says NVIDIA. The logo is the official horizontal logo (SVG) published on NVIDIA’s "Logo and Brand Usage" page, used as obtained. Isaac, GR00T (which the 2024 press release says stands for Generalist Robot 00 Technology), Jetson, Cosmos, DRIVE and Alpamayo are product or model names, not company names. Isaac Lab and Isaac Sim are separate products: the first is for training robots and the second is a physics-simulation framework.
Official site: https://www.nvidia.com/en-us/about-nvidia/legal-info/logo-brand-usage/3. Where the company sits in the field
NVIDIA’s main type is "Components & enabling software" at the far right. It does not build robot bodies; it supplies parts and foundations that any robot can use: compute (chips and embedded modules), simulation and AI models. Because it also publishes open models for humanoid robots (GR00T), it has traits of "Humanoids & physical AI" at the far left too Our calculation. This article does not reuse the text of NVIDIA’s profile in the AI and machine learning field; it is written afresh from primary sources on robotics and driving.
4. Scale (limited to robotics and driving)
NVIDIA is huge, but this article’s subject is robotics and self-driving. We show company-wide scale briefly and focus on figures that touch this field Sourced. Mind the fiscal-year labels: FY2026 ran from 27 January 2025 to 25 January 2026.
| Metric | FY2024 | FY2025 | FY2026 |
|---|---|---|---|
| Company revenue (US$ millions) | 60,922 | 130,497 | 215,938 |
| R&D spending (US$ millions) | 8,675 | 12,914 | 18,497 |
| Automotive end-market revenue (US$ millions) | 1,091 | 1,694 | 2,349 |
| Robotics revenue | Not disclosed | Not disclosed | Not disclosed |
| Item | Content | Type |
|---|---|---|
| Employees | About 42,000 at the end of FY2026 (38 countries), about 31,000 of them in R&D | Sourced |
| What "Automotive" covers | Platform solutions for automated driving from cloud to car (DRIVE Hyperion and others). FY2026 revenue was up 39% on the prior year, which the company attributes to continued adoption of its self-driving platforms | Sourced |
| Change in presentation | From the first quarter of FY2027, markets are shown as "Data Center" and "Edge Computing". Edge Computing means devices such as PCs, game consoles, workstations, AI-RAN base stations, robotics and automotive. Its revenue was US$6.4 billion in the first quarter and US$7.2 billion in the second | Sourced |
The figures above are for the whole company or for end markets. They are not robotics revenue. The new FY2027 category "Edge Computing" (US$7.2 billion in the second quarter) also includes non-robot devices such as PCs and game consoles, so it does not show the size of robotics. NVIDIA does not disclose robotics revenue or shipments, and we do not estimate them. Nothing here touches share price or valuation.
5. Resources behind robotics and driving
We sort four resource types (people, money, outside investments and acquisitions, and ties to universities or public bodies) by whether primary sources let us confirm them. "Not mentioned" is itself a finding.
| Resource | Content | Type |
|---|---|---|
| People | About 42,000 in total, about 31,000 in R&D (end of FY2026). Headcount specific to robotics and driving is not disclosed | Sourced |
| Money | Company R&D spending was US$18.497 billion in FY2026; the part for robotics and driving is not disclosed. Cloud-service commitments as of 26 July 2026 total US$29 billion, which the company describes as supporting R&D of open models such as Nemotron, Cosmos and GR00T and of its autonomous-vehicle software (not a robotics-only figure) | Sourced |
| Outside investments, acquisitions, joint ventures | NVIDIA’s investment arm (NVentures) took part in the Series C (January 2026) of Skild AI, a robot foundation-model company (Skild AI’s announcement). We could not confirm a robotics- or driving-specific acquisition in the relevant parts of the 10-K and 10-Qs we checked | Sourced (investment) / Not confirmed (acquisitions) |
| Universities, research institutes, public bodies | The official pages, 10-K and 10-Qs we checked mention no research agreements with universities or public bodies on robotics or driving | Not confirmed |
| Releases to developers | GR00T, Cosmos, Alpamayo, Isaac Sim and Isaac Lab are published on GitHub and elsewhere (licenses in Chapter 10). Training courses for developers are offered | Sourced |
Status of the main products (checked 25 October 2026)
| Name | Kind | Main specifications (company’s statements) | Use and operating record | Regulatory approval | Stage and date |
|---|---|---|---|---|---|
| Isaac GR00T N1.7 | Open VLA model for humanoid robots | Takes camera video, a language command and joint state, and outputs chunks of motion. Backbone is Cosmos-Reason2-2B (2B-class by name). Pre-trained with 20,000 hours of human first-person video. Runs at about 40 Hz on an RTX PRO 6000 Blackwell Server Edition and about 28 Hz on Jetson AGX Thor (batch 1, company measurement) | No customer deployments found in the materials | Not applicable (software) | Released. The GitHub README says General Availability, while the developer page still describes Early Access (no commercially supported production use), so the two do not agree |
| Isaac GR00T N1 (first version) | Model for humanoid robots | A dual structure: a vision-language part (System 2) and a diffusion part that produces motion (System 1). Trained on robot trajectories, human video and synthetic data (paper) | Language-conditioned bimanual tasks on a Fourier GR-1 humanoid (paper) | Not applicable | Announced; 18 March 2025 (paper). The precursor, Project GR00T, was announced on 18 March 2024 |
| Jetson AGX Thor | Computer built into robots | Blackwell GPU, 128 GB memory, up to 2,070 TFLOPS of AI compute (FP4), 130 W power envelope. Up to 7.5 times the AI compute and 3.5 times the energy efficiency of AGX Orin (company figures, stated as "up to") | Available. No customer names in the official materials we checked | Described as including functional safety (scope not confirmed) | Available; 25 August 2025 (developer kit and T5000 module) |
| Isaac Sim / Isaac Lab | Frameworks for robot simulation and training | Isaac Sim does testing and data generation in physically based virtual environments. Isaac Lab 3.0.0 covers reinforcement and imitation learning, actuator models and domain randomization (paper and README) | Skild AI says it uses them in pre-training (Skild AI blog) | Not applicable | Available (open source). The Isaac Lab paper is dated 6 November 2025 |
| Cosmos 3 / Cosmos3-Edge | World models (AI that predicts and generates real-world motion) | A family of models for language, images, video, sound and action. The Edge version is about 4 billion parameters, aimed at Jetson AGX Orin and Thor and RTX PRO 6000. The company says long outputs can show object deformation or implausible motion | Used for data generation, evaluation and policy learning, the company says | Not applicable; the company says safety-critical uses need extra validation | Available; Cosmos 3 in May 2026, the Edge version in July 2026 (README) |
| DRIVE Hyperion / DRIVE AGX / DriveOS | In-vehicle compute and base software for self-driving | DRIVE AGX (Orin and Thor), a "safety-certified" in-vehicle OS (DriveOS), a reference sensor set (10-K) | Several hundred automotive ecosystem partners (10-K). Specific vehicle models were not confirmed in the materials we checked | DriveOS is described as safety-certified; the type and scope of certification are not given (not confirmed) | Available |
| Alpamayo 1 Nano | Open reasoning VLA model for self-driving | About 10 billion parameters; pairs driving trajectories with chain-of-causation reasoning. The GitHub license is Apache-2.0 | For research and developers. The README says focus is moving to newer versions | Not applicable | Released; repository created 19 November 2025 |
The figures in this table are values NVIDIA measured on its own hardware and conditions, or the company’s own descriptions. Conditions differ by product, so the rows cannot be lined up to rank anything. For deployment and demonstration claims, whether the work was autonomous or remotely operated, unit counts and independent verification could not be confirmed on the official pages.
Reading NVIDIA’s materials with a materials eye, two points stand out. The first is heat. The company says Jetson AGX Thor delivers up to 2,070 TFLOPS (FP4) within a 130-watt envelope Sourced. A robot runs on a battery, so the power its computer draws and the heat it gives off bear directly on battery life and on how much heat-dissipation hardware fits inside the body. In general, in a small machine the choice of heat-handling materials (materials that spread heat, sheet-like materials that bridge surfaces) is likely to matter. But the company’s materials give no specifics on how robots carrying Thor handle heat or which materials they use, so this is our own interpretation Not yet confirmed.
The second is materials inside simulation. Isaac Sim’s description says it takes design data (CAD, URDF), assigns materials and enables physics, and assembles scenes. The Isaac Lab paper says it includes actuator models and domain randomization (deliberately varying conditions while learning). The gap between simulation and the real machine (the sim-to-real gap) often comes from differences in physical property values such as friction and stiffness, and this is where materials knowledge can help.
6. Track record so far
| When | What happened | Meaning |
|---|---|---|
| 18 Mar 2024 | Project GR00T (a foundation model for humanoid robots), the robot computer Jetson Thor and Isaac updates announced | Public start of its humanoid-robot push |
| 7 Jan 2025 | Paper on the Cosmos world-foundation-model platform published (open weights) | World models made open |
| 18 Mar 2025 | The GR00T N1 paper published; the Isaac GR00T platform introduced at GTC 2025 | An open model for humanoid robots |
| 25 Aug 2025 | Jetson AGX Thor developer kit and T5000 module became available; GR00T N1.5 supported | The robot computer becomes a product |
| 6 Nov 2025 | Isaac Lab paper published | The training framework described |
| 19 Nov 2025 | GitHub repository for the self-driving Alpamayo created | An open model for self-driving |
| 19 Mar 2026 | Skild AI’s announcement describes use of Isaac Lab, Isaac Sim and Cosmos and a Foxconn assembly-line example (Skild AI blog) | An example of another company using NVIDIA’s training stack |
| May and Jul 2026 | Cosmos 3 and Cosmos3-Edge released (README) | A new world-model generation and a small on-device version |
| 2026 (as of the check date) | GR00T N1.7 is the latest (README says General Availability). The new backbone is Cosmos-Reason2-2B | A model generation change. The README gives no release date |
| 20 May and 26 Aug 2026 | Quarterly reports change the market split (Edge Computing includes robotics and automotive) | Robotics still does not become its own line |
7. Plans
In its 10-K and 10-Qs, NVIDIA gives no release dates or shipment targets for robotics products. Only fragments of per-product direction appear on developer pages and GitHub Not yet confirmed. For GR00T N1.7, the developer page describes Early Access ahead of a full commercial release, while GitHub says General Availability, so the two statements do not agree. We do not decide which is current and give both.
None of the following appears in official materials Not yet confirmed.
Robotics revenue and shipments / the number of companies using GR00T, Thor or Cosmos / Jetson Thor’s list price (not checked in this article) / the date of commercial release of GR00T N1.7 / R&D spending and headcount limited to robotics and driving. We do not use press-reported figures.
8. What the company seems to be aiming for
This chapter includes points the company does not state directly. They are inferences that stay within what primary sources allow, given with their grounds.
| What can be read | Primary-source basis | Type |
|---|---|---|
| It aims to provide all three stages (train, simulate, run) from one company | The GR00T developer page lays out Train (DGX Cloud), Simulate (Omniverse, Cosmos, RTX PRO 6000) and Deploy (Jetson Thor). The 10-K also says it provides this from data center to embedded modules | Sourced (company’s description) |
| Open models are also a way to widen demand for its own computers | It publishes GR00T, Cosmos and Alpamayo, and the training and running of them assume its own GPUs and embedded computers. The 10-Q discloses cloud commitments tied to developing them | Inference |
| It wants robot makers to be able to start without building a model from scratch | It says GR00T includes data from several robots (Unitree G1, AgiBot Genie-1, Fourier GR-1 and others) and adapts to a new machine with a few recorded demonstrations | Sourced (company’s description) |
| Robotics is likely still small within company revenue | FY2026 automotive revenue was about 1% of the total (US$2.35 billion of US$215.9 billion). Robotics has no separate line and is not disclosed | Inference (the 1% is our calculation) |
The reading that "robotics is probably still small within company revenue" rests on how the numbers appear. In the 10-K’s revenue by end market, Data Center is US$193.7 billion and Automotive, which includes self-driving, is US$2.35 billion, about 1.1% of the total (our calculation Our calculation). Robotics has no line of its own, and in the new FY2027 split it sits in "Edge Computing" alongside PCs and game consoles. From this we read that robotics is probably not at a scale that moves the whole company’s revenue. However, the 10-K says that, to support market development, the company has accelerated releases of open models for physical AI such as Cosmos. A small amount of money and low strategic importance are different things. The actual amount cannot be confirmed from official materials Not yet confirmed.
9. Partnership map
| Counterparty | Relationship (as stated in official materials) | Note |
|---|---|---|
| Skild AI | Skild AI says it builds physically accurate simulation with Isaac Lab and Isaac Sim and makes synthetic data with Cosmos. It also says S1 was built on NVIDIA AI infrastructure (S1 post). NVentures (NVIDIA) took part in its Series C | Based on Skild AI’s statements. Two relationships: supplier and investor |
| Foxconn | An example in which Skild AI’s model handles two-armed assembly on a line for NVIDIA Blackwell systems (Skild AI’s announcement) | Not confirmed in NVIDIA’s own materials; no unit counts or hours given |
| Universal Robots | Its head (titled CEO in Skild AI’s post) said that working with Skild AI and NVIDIA lets cobots take on more variable tasks (a quotation inside Skild AI’s post) | A remark quoted in Skild AI’s article |
| Unitree, AgiBot, Fourier | The GR00T N1.6 training data includes the Unitree G1, AgiBot Genie-1 and Fourier GR-1 (GR00T developer page). GR00T N1 was shown doing real tasks on the Fourier GR-1 (paper) | These are target machines for data; any business agreement is not stated |
| Hugging Face | The developer page points to it as the place to download GR00T weights | A download location; the nature of any partnership is not stated |
| Carmakers and others | The 10-K cites "long-standing relationships across several hundred automotive ecosystem partners" in self-driving | Company names and models not confirmed in the materials we checked |
10. Technologies, products and services
NVIDIA’s robotics and driving products fit three stages: train, simulate, run. Here are the main elements that the official developer pages, 10-K, GitHub and papers let us confirm Sourced.
| Element | Plain explanation | Place in official materials |
|---|---|---|
| GR00T | An AI that produces a humanoid robot’s motion: from camera video and a language instruction to chunks of motion | N1.7 released under Apache-2.0; paper available (arXiv 2503.14734) |
| Cosmos | A "world model" that predicts and generates real-world motion; used for data synthesis, evaluation and policy learning | Released under OpenMDW-1.1; paper available (arXiv 2501.03575); the company states safety limits |
| Isaac Sim | A framework for trying robots in a physically based virtual environment | The developer page describes open source under Apache 2.0 |
| Isaac Lab | A framework for training robot policies with reinforcement and imitation learning | README states Apache-2.0; paper available (arXiv 2511.04831) |
| Jetson AGX Thor | A small computer that runs AI in real time inside the robot’s body | Available since 25 August 2025; up to 2,070 TFLOPS (FP4) in a 130 W envelope (company’s figure) |
| DRIVE and Alpamayo | In-vehicle computer and OS for self-driving, and an open model that reasons about driving | DRIVE AGX, DriveOS, Alpamayo 1 Nano (Apache-2.0) |
GR00T, Cosmos and Alpamayo are released openly, but the license differs by model (Apache-2.0, OpenMDW-1.1 and so on). Read each repository’s license text before use. NVIDIA also states in the Cosmos description that long outputs can show deformed objects or implausible motion and that safety-critical uses need additional validation. Nor does a simulation result guarantee the same behaviour on a real machine. For robots and self-driving, testing on real hardware and a separate safety assessment are needed (see also our explainers on how to read robot safety standards and on robot simulation and digital twins).
11. Risks the company faces
| Risk | Content | Type |
|---|---|---|
| Robotics scale cannot be seen from outside | Revenue, shipments and the number of adopters are undisclosed, so a third party can hardly check the reality of the business | Sourced |
| Inconsistent public information | GR00T N1.7 is described as General Availability on GitHub and as Early Access on the developer page (as of the check date) | Sourced |
| Automotive regulation | The 10-Q says U.S. "Connected Vehicle" restrictions could affect its ability to develop and supply solutions for automotive customers | Sourced |
| Validation for safety-critical uses | The Cosmos description says safety-critical uses need extra validation. Development centred on simulation presupposes testing on real hardware | Sourced (company’s description) |
| Dependence on its own compute | The open models and training stack assume NVIDIA’s own GPUs and embedded computers; more alternatives could change that position | Inference |
| Similar models exist elsewhere | Other companies, such as Physical Intelligence and Skild AI, also build robot foundation models (see the profiles in this series). This article does not rank them | Inference |
12. Glossary
- Physical AI
- AI that handles real objects, not only things on a screen: robots, self-driving and the like.
- VLA
- Vision-language-action model: turns images and a language instruction directly into robot motion.
- World model
- AI that predicts or generates how the real world changes (how things move). Cosmos is one.
- Simulation
- Trying out robot motion in huge numbers inside a virtual space on a computer.
- Sim-to-real
- Carrying what was learned in simulation over to a real machine, or the gap between the two.
- Domain randomization
- Deliberately varying simulation conditions (friction, weight) so that the result is robust to real-world differences.
- Jetson
- NVIDIA’s series of small AI computers for robots and devices.
- DRIVE
- NVIDIA’s family of computers and software for self-driving.
- FP4
- A 4-bit number format that makes AI computation faster and smaller. The performance figure is the maximum under this condition.
- 10-K and 10-Q
- Annual and quarterly reports filed with the U.S. SEC; disclosures for which the company is legally responsible.
- Edge computing
- Computing on the device instead of in a data center. Also the name of NVIDIA’s new market category.
- Open model
- A model whose weights or code are published. The license terms must be checked individually.
13. References
- NVIDIA Form 10-K for the fiscal year ended 25 January 2026 (filed with the U.S. SEC on 25 February 2026). Company-wide revenue, R&D spending and headcount, revenue by end market, and the description of physical AI and autonomous driving. https://www.sec.gov/Archives/edgar/data/1045810/000104581026000021/nvda-20260125.htm
- NVIDIA Form 10-Q for the quarter ended 26 April 2026 (filed 20 May 2026). The change in market presentation (Edge Computing includes robotics and automotive). https://www.sec.gov/Archives/edgar/data/1045810/000104581026000052/nvda-20260426.htm
- NVIDIA Form 10-Q for the quarter ended 26 July 2026 (filed 26 August 2026). Edge Computing revenue, cloud commitments for open models, automotive regulatory risk. https://www.sec.gov/Archives/edgar/data/1045810/000104581026000075/nvda-20260726.htm
- NVIDIA Press release announcing Project GR00T, Jetson Thor and Isaac updates (18 March 2024). https://nvidianews.nvidia.com/news/foundation-model-isaac-robotics-platform
- NVIDIA Isaac GR00T developer page. Components, inputs and outputs, training data, and the Early Access description. https://developer.nvidia.com/isaac/gr00t
- NVIDIA GitHub: NVIDIA/Isaac-GR00T. README for GR00T N1.7, license (Apache-2.0), speeds. https://github.com/NVIDIA/Isaac-GR00T
- arXiv GR00T N1: An Open Foundation Model for Generalist Humanoid Robots (2503.14734, 18 March 2025). https://arxiv.org/abs/2503.14734
- NVIDIA Introducing NVIDIA Jetson Thor, the Ultimate Platform for Physical AI (technical blog, 25 August 2025). Specifications and availability. https://developer.nvidia.com/blog/introducing-nvidia-jetson-thor-the-ultimate-platform-for-physical-ai/
- NVIDIA Isaac Sim developer page. Robot simulation, assigning materials, license. https://developer.nvidia.com/isaac/sim
- NVIDIA GitHub: isaac-sim/IsaacLab. README for Isaac Lab 3.0.0 and license. https://github.com/isaac-sim/IsaacLab
- arXiv Isaac Lab: A GPU-Accelerated Simulation Framework for Multi-Modal Robot Learning (2511.04831, 6 November 2025). https://arxiv.org/abs/2511.04831
- NVIDIA GitHub: NVIDIA/Cosmos. Update history for Cosmos 3 and Cosmos3-Edge, license, and statements on limits and safety. https://github.com/NVIDIA/Cosmos
- arXiv Cosmos World Foundation Model Platform for Physical AI (2501.03575, 7 January 2025). https://arxiv.org/abs/2501.03575
- NVIDIA NVIDIA DRIVE developer page. DRIVE AGX, DriveOS, Alpamayo. https://developer.nvidia.com/drive
- NVIDIA GitHub: NVlabs/alpamayo. An open reasoning model for autonomous driving (about 10 billion parameters). https://github.com/NVlabs/alpamayo
- Skild AI The Reindustrial Revolution (19 March 2026). The NVIDIA and Foxconn assembly-line example, and use of Isaac and Cosmos. https://www.skild.ai/blogs/reindustrial-revolution
- Skild AI Announcing Series C (14 January 2026). Participation of NVentures (NVIDIA). https://www.skild.ai/blogs/series-c
- Skild AI Introducing S1 (18 August 2026). The statement that S1 was built on NVIDIA AI infrastructure. https://www.skild.ai/blogs/s1
- NVIDIA Logo and Brand Usage (source of the logo). https://www.nvidia.com/en-us/about-nvidia/legal-info/logo-brand-usage/
14. Claim-to-source audit
| Claim in the text | Type | Source |
|---|---|---|
| Listing (NASDAQ: NVDA) and headquarters (Santa Clara) | Sourced | Reference 1 https://www.sec.gov/Archives/edgar/data/1045810/000104581026000021/nvda-20260125.htm |
| Revenue, R&D spending and automotive revenue (FY2024 to FY2026); about 42,000 employees | Sourced | Reference 1 https://www.sec.gov/Archives/edgar/data/1045810/000104581026000021/nvda-20260125.htm |
| The description of a physical-AI platform from data center to modules | Sourced | Reference 1 https://www.sec.gov/Archives/edgar/data/1045810/000104581026000021/nvda-20260125.htm |
| DRIVE Hyperion, several hundred automotive ecosystem partners, automotive revenue up 39% | Sourced | Reference 1 https://www.sec.gov/Archives/edgar/data/1045810/000104581026000021/nvda-20260125.htm |
| Definition of Edge Computing (includes robotics and automotive) and Q1 revenue of US$6.4 billion | Sourced | Reference 2 https://www.sec.gov/Archives/edgar/data/1045810/000104581026000052/nvda-20260426.htm |
| Edge Computing Q2 revenue of US$7.2 billion, breakdown of the US$29 billion cloud commitments, Connected Vehicle regulatory risk | Sourced | Reference 3 https://www.sec.gov/Archives/edgar/data/1045810/000104581026000075/nvda-20260726.htm |
| Announcement of Project GR00T and Jetson Thor (18 March 2024) and the meaning of the GR00T name | Sourced | Reference 4 https://nvidianews.nvidia.com/news/foundation-model-isaac-robotics-platform |
| GR00T structure (Train, Simulate, Deploy), inputs and outputs, training data, Early Access description | Sourced | Reference 5 https://developer.nvidia.com/isaac/gr00t |
| GR00T N1.7 (Apache-2.0, 40 Hz and 28 Hz, Cosmos-Reason2-2B, 20,000 hours of human video) and the General Availability statement | Sourced | Reference 6 https://github.com/NVIDIA/Isaac-GR00T |
| Structure of GR00T N1, real-robot work on the Fourier GR-1, 18 March 2025 | Sourced | Reference 7 https://arxiv.org/abs/2503.14734 |
| Jetson AGX Thor specifications (2,070 TFLOPS, 130 W, 128 GB memory) and availability (25 August 2025) | Sourced | Reference 8 https://developer.nvidia.com/blog/introducing-nvidia-jetson-thor-the-ultimate-platform-for-physical-ai/ |
| Isaac Sim description (assigning materials, Apache 2.0) | Sourced | Reference 9 https://developer.nvidia.com/isaac/sim |
| Isaac Lab 3.0.0 README and license (Apache-2.0) | Sourced | Reference 10 https://github.com/isaac-sim/IsaacLab |
| Isaac Lab paper (actuator models, domain randomization, planned Newton integration) | Sourced | Reference 11 https://arxiv.org/abs/2511.04831 |
| Cosmos 3 (May 2026) and Cosmos3-Edge (July 2026), OpenMDW-1.1, statements on limits and safety | Sourced | Reference 12 https://github.com/NVIDIA/Cosmos |
| Cosmos platform paper (7 January 2025, open weights) | Sourced | Reference 13 https://arxiv.org/abs/2501.03575 |
| DRIVE AGX, DriveOS (safety-certified) and Alpamayo | Sourced | Reference 14 https://developer.nvidia.com/drive |
| Alpamayo 1 Nano scale (about 10 billion parameters), Apache-2.0, repository creation date | Sourced | Reference 15 https://github.com/NVlabs/alpamayo |
| Skild AI’s use of Isaac and Cosmos, the NVIDIA and Foxconn assembly example, and a remark by Universal Robots’ head | Sourced | Reference 16 https://www.skild.ai/blogs/reindustrial-revolution |
| NVentures (NVIDIA) taking part in Skild AI’s Series C | Sourced | Reference 17 https://www.skild.ai/blogs/series-c |
| The statement that S1 was built on NVIDIA AI infrastructure | Sourced | Reference 18 https://www.skild.ai/blogs/s1 |
| Source of the logo (official horizontal logo) | Sourced | Reference 19 https://www.nvidia.com/en-us/about-nvidia/legal-info/logo-brand-usage/ |
| Robotics revenue and shipments, number of adopters, robotics-only R&D spending and headcount | Not yet confirmed | Not in official materials; we do not estimate https://www.sec.gov/Archives/edgar/data/1045810/000104581026000021/nvda-20260125.htm |
| Date of commercial release of GR00T N1.7, Jetson Thor’s price | Not yet confirmed | Could not be confirmed in official materials https://developer.nvidia.com/isaac/gr00t |
| Robotics or driving acquisitions, and research agreements with universities or public bodies | Not yet confirmed | Not found in the parts we checked; we do not assert that none exist https://www.sec.gov/Archives/edgar/data/1045810/000104581026000075/nvda-20260726.htm |
| Four-type classification (main: Components & enabling software; secondary: Humanoids & physical AI); automotive revenue as about 1.1% of the total | Our calculation | Our own classification and calculation (US$2.349 billion / US$215.938 billion) |
| The reading that open models are also a way to widen demand for its own computers | Inference | Our own reading (basis: Reference 3 https://www.sec.gov/Archives/edgar/data/1045810/000104581026000075/nvda-20260726.htm) |
| The reading that robotics is probably still small within company revenue | Inference | Our own reading (basis: References 1 and 2 https://www.sec.gov/Archives/edgar/data/1045810/000104581026000021/nvda-20260125.htm) |
| The risks of dependence on its own compute and of similar models elsewhere | Inference | Our own reading, based on other profiles in this series |
Last updated: 25 October 2026 / Troy Technical
This article rests on NVIDIA’s 10-K and 10-Qs filed with the U.S. SEC, NVIDIA’s official pages, GitHub and papers, and Skild AI’s official blog. We use no market-research estimates or press-reported figures. Product performance figures are the company’s stated values under stated conditions, not independent verification. This is not investment advice and does not touch share price or valuation. Passages marked "Inference" are our own readings of primary sources and are not statements by the company.