TECHNOLOGY EXPLAINER
Autonomous Driving and AI
— reading "what it can drive" and "how that is shown" with levels, dates and conditions aligned
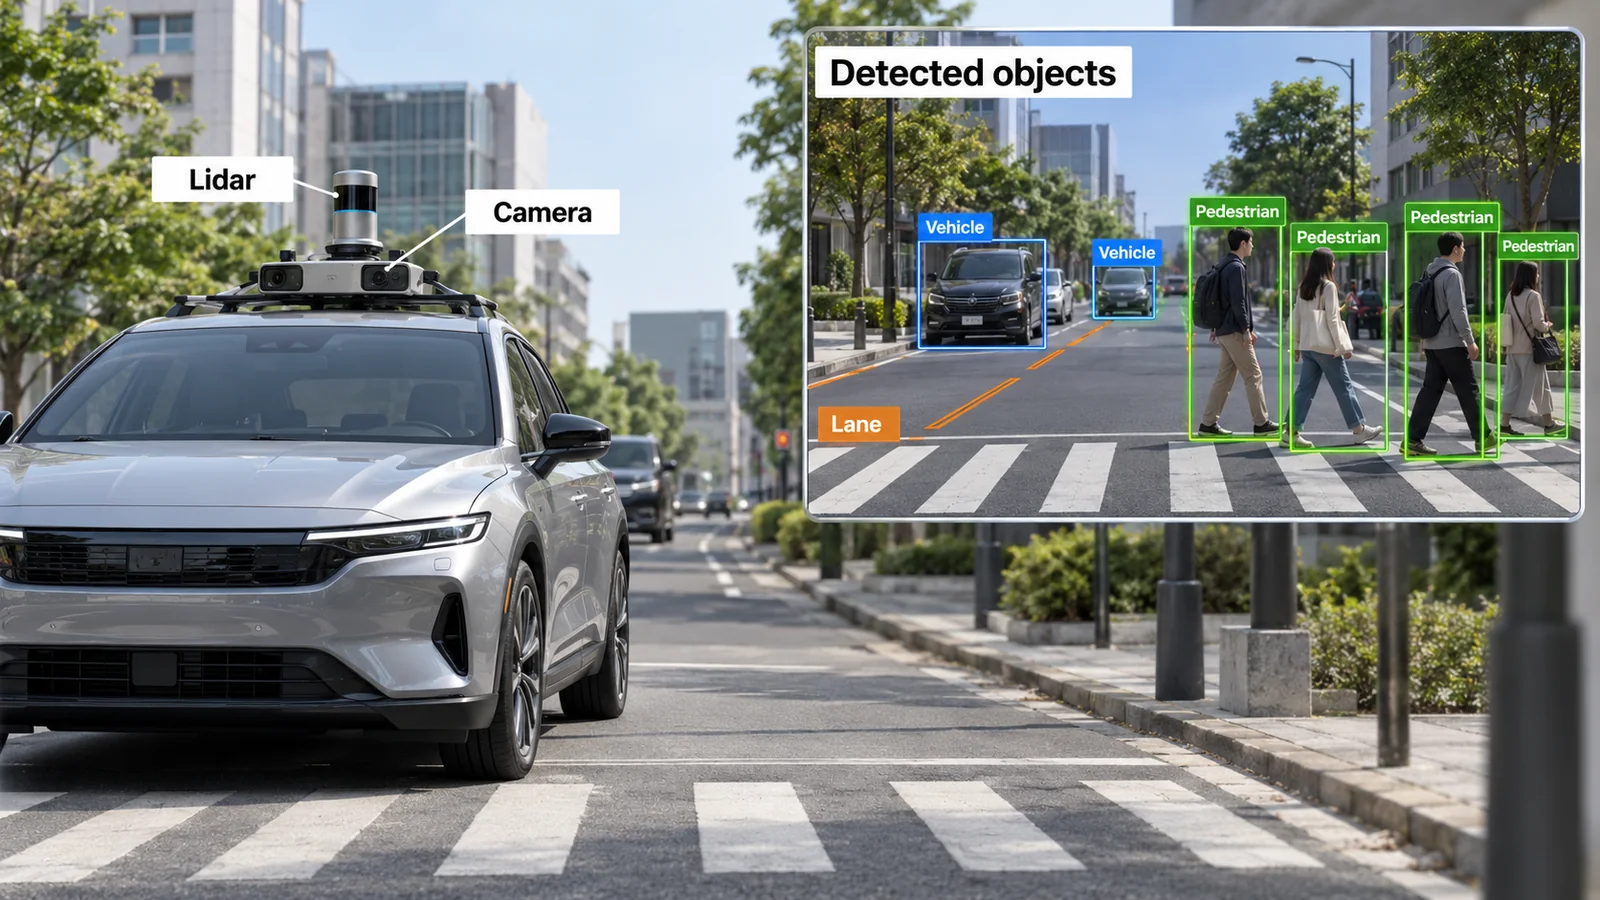
Autonomous driving is a field in which AI handles perception, prediction and planning and safety is checked through standards, regulation and on-road data. When the level (SAE level), the area it may operate in (operational design domain, ODD), the dates on which regulations were adopted or took effect, and the method of evaluation (log replay, simulation or on-road driving) get mixed together, words like "self-driving is here" and "it is safe" mean different things to different people. Using official material from SAE, ISO, UNECE (the United Nations), the EU, Japan and the United States, and papers on evaluation datasets, this article sorts these out. It does not assert causes of individual accidents by guesswork, and it neither recommends nor blames any company.
- Autonomous driving and AI (the short version)
- Levels (SAE) and the operational design domain (ODD): the September 2026 revision
- Perception, prediction and planning: modular and end-to-end
- Levels of evaluation: log replay, non-reactive simulation, closed loop and on-road driving
- Approaches to safety: functional safety, SOTIF, AI safety, ADS safety and scenario evaluation
- Regulation by stage and date: adoption, entry into force and expectations
- On-road data and "how many miles it takes to show it"
- Limits, and what could not be confirmed
- How to read evaluations and standards
- Glossary
- References
- Claim-to-source audit
Sourced = stated in a published source (linked)
Our calculation = a value this article derives from stated assumptions
Not yet confirmed = plans, schedules or proposals not yet confirmed as results
Interpretation and organization are marked as commentary. An inference is shown in bold.
The safety and performance figures here are values reported by operators or researchers for a specific place, period, vehicle and set of conditions. Reports written by operators themselves are kept apart from independent verification. For regulation we separate the stages of "proposal, adoption (agreement) and entry into force (application)" with dates, and treat expected dates as "not yet confirmed". Causes of individual accidents are not guessed at without an official investigation report. No company or product is recommended or blamed. Our calculation is a simple statistical guide, not proof of safety. This is not legal, design or operational advice.
1. Autonomous driving and AI (the short version)
- Level and operating area are different things: SAE J3016 defines driving automation in levels 0 to 5, and a revision, J3016_202609, became "current" on 20 September 2026. The short level descriptors changed, but the page itself says they are not the definitions.Sourced[Ref. 1] The conditions in which it may run (the ODD) are set separately from the level.
- Read regulation by stage and date: the UN's WP.29 agreed on 23 to 26 June 2026 an international standard for automated driving systems including levels 3 and 4, and Japan's MLIT expects it to take effect around January 2027 (an expectation).Sourced[Ref. 7] The EU has had a type-approval rule for limited use cases since 2022,Sourced[Ref. 9] and Japan's level 4 permit system took effect in April 2023.Sourced[Ref. 10]
- Safety cannot be shown by miles driven alone: the U.S. fatality rate in 2024 was 1.19 per 100 million miles.Sourced[Ref. 12] In our calculation, merely claiming with 95% confidence that the rate is at or below that level with zero fatalities needs about 252 million miles (Chapter 7).Our calculation RAND said in 2016 that driving alone is hard as a way to show safety and that other methods are needed.Sourced[Ref. 13]
"Autonomous driving" can be compared only once it is stated which of the level (SAE), the operating conditions (ODD), the regulatory stage (adopted or in force) and the evaluation method (logs, simulation or on-road) is meant. Even under the same word "safe", the planning error measured by replaying logs and the crash rate on the road are different quantities.
2. Levels (SAE) and the operational design domain (ODD): the September 2026 revision
SAE J3016 divides driving automation systems into levels 0 to 5 by how much of the dynamic driving task (DDT, the real-time functions of operating a vehicle such as steering, speed control and monitoring surroundings) they perform. SAE's page shows that the current J3016_202609 (revised 20 September 2026) changes the short descriptors as follows: level 0, no driving automation; level 1, driver support for steering OR speed with continual driver supervision; level 2, driver support for steering AND speed with continual driver supervision; level 3, automated driving under defined conditions with human driving needed following an alert or evident vehicle malfunction; level 4, automated driving under defined conditions with human driving not needed to mitigate risk; and level 5, automated driving under all conditions in which humans can drive. The page says these descriptors are not the definitions, which are in Sections 4 and 5 of the standard.Sourced[Ref. 1] (The wording above is our paraphrase.) The April 2021 edition (J3016_202104) is classed as "historical".Sourced[Ref. 1]
The ODD (operational design domain) is the range of conditions in which an automated driving system is designed to operate. EU Implementing Regulation 2022/1426 defines an automated driving system (ADS) as the hardware and software collectively capable of performing the entire DDT on a sustained basis in a specific ODD, and an "ADS feature" as an application designed for a specific use within an ODD.Sourced[Ref. 9] The scenario-based safety evaluation framework of ISO 34502:2022 states that it applies to limited access highways.Sourced[Ref. 6] What an ODD actually contains (road types, speeds, weather, time of day, geographic area) differs by system (our commentary).
3. Perception, prediction and planning: modular and end-to-end
The conventional structure is modular: perception (detecting and tracking objects), prediction (the movement of other vehicles and pedestrians), planning (the own route) and control in sequence. UniAD (Hu et al., 2022) proposes a framework that brings perception, prediction and planning into one network oriented toward the final goal of planning, and reports outperforming earlier work on the nuScenes benchmark (the authors' report).Sourced[Ref. 21] EMMA (Hwang et al., Waymo, 2024) builds on a multimodal large language model to output planner trajectories, objects and road graphs directly from camera images, and reports state-of-the-art motion planning on nuScenes and competitive results on the Waymo Open Motion Dataset (the authors' report).Sourced[Ref. 22] The survey by Chen et al. organizes the challenges and prospects of end-to-end driving.Sourced[Ref. 24]
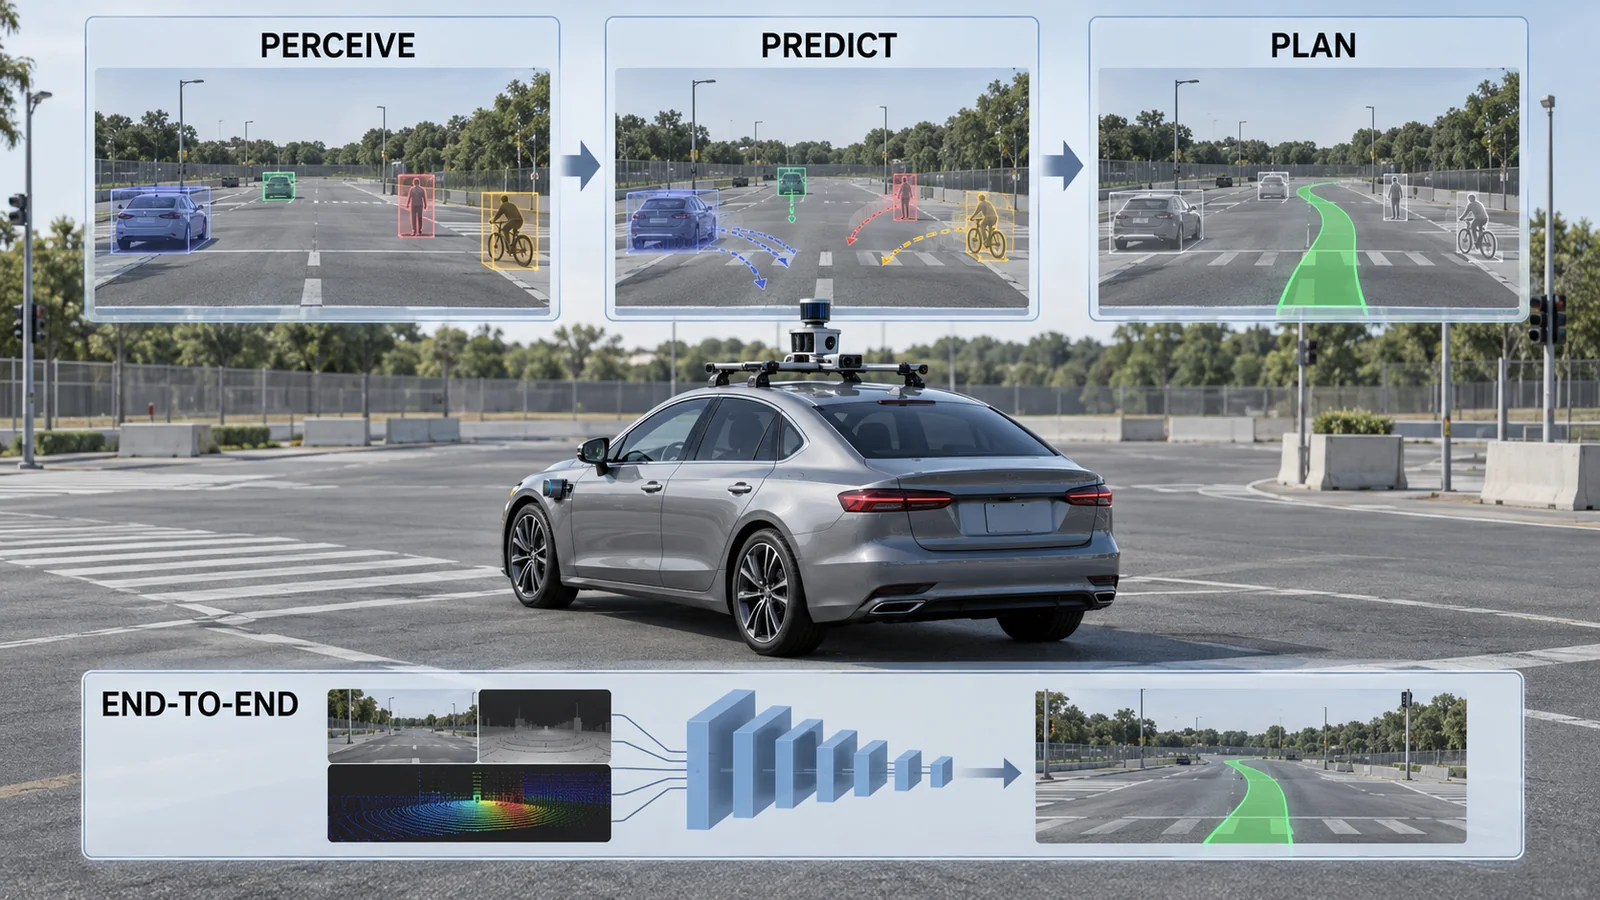
View original SVG, values and source annotations
Li et al. analyzed that, in log replay (open-loop) on nuScenes, end-to-end methods tend to plan future paths by relying on the ego vehicle's status such as its speed and under-use perception information. They add that current metrics do not comprehensively assess planning quality and can lead to biased conclusions from existing benchmarks, and suggest being cautious about whether pursuing state of the art yields convincing and universal conclusions.Sourced[Ref. 23] In other words, good log-replay numbers do not necessarily show good closed-loop driving, where the vehicle's actions change the next situation (the authors' analysis).
4. Levels of evaluation: log replay, non-reactive simulation, closed loop and on-road driving
Evaluating driving AI splits into several levels, trading realism against cost. The NAVSIM paper observes that open-loop evaluation with real data is easy but does not reflect closed-loop performance, while closed-loop evaluation in simulation is computationally heavy and has a large domain gap to real data, and proposes a middle ground combining large real datasets with a "non-reactive" simulator in which the evaluated policy and the environment do not influence each other.Sourced[Ref. 18] Bench2Drive, noting that many end-to-end methods are evaluated by open-loop log replay with L2 error and collision rate and that driving scores on fixed routes in closed loop are high-variance metrics, proposes a multi-ability closed-loop benchmark.Sourced[Ref. 19]
| Dataset / benchmark | Content (as stated in the paper) | What to watch |
|---|---|---|
| nuScenes (Caesar et al., 2019) | Full 360-degree sensor suite of 6 cameras, 5 radars and 1 lidar, 1,000 scenes of 20 s each, 3D boxes for 23 classes and 8 attributes; defines 3D detection and tracking metrics [15] | Limited capture regions (Boston and Singapore) and sensor configuration. For planning evaluated by log replay, see the caution in Chapter 3 [23] |
| Waymo Open Dataset (Sun et al., 2019) | 1,150 scenes of 20 s each, synchronized and calibrated LiDAR and camera data with 2D and 3D boxes, across urban and suburban regions [16] | The paper states it is 15x more diverse than the largest camera+LiDAR dataset on its proposed diversity metric (authors' claim) |
| nuPlan (Caesar et al., 2021) | 1,500 hours of human driving data (Boston, Pittsburgh, Las Vegas, Singapore), a lightweight closed-loop simulator and planning metrics [17] | The paper calls it the world's first closed-loop ML-based planning benchmark (authors' claim) |
| CARLA (Dosovitskiy et al., 2017) | An open urban driving simulator [20] | A domain gap to reality remains (noted in the NAVSIM paper [18]) |
| Bench2Drive (Jia et al., 2024) | A multi-ability closed-loop benchmark for end-to-end methods [19] | The authors call it the first; it addresses the high variance of fixed-route driving scores |
| NAVSIM (Dauner et al., 2024) | Computes metrics such as progress and time to collision from real data and a non-reactive simulator [18] | Being non-reactive, it cannot evaluate scenes in which other agents react to the ego vehicle (as described in the paper) |
All Sourced (a summary of each paper's statements; "first" and "largest" are the authors' claims).
5. Approaches to safety: functional safety, SOTIF, AI safety, ADS safety and scenario evaluation
Autonomous-driving safety is handled from several angles by the ISO/TC 22 (road vehicles) family of standards. The following were confirmed on ISO pages for title, edition and status (checked 15 October 2026). The texts are paid; only the abstracts are paraphrased.
| Standard | What it covers (as in the ISO page abstract) | Edition and status (ISO page) |
|---|---|---|
| ISO 26262-1:2018 | Functional safety. Applies to safety-related systems with electrical and/or electronic (E/E) systems in series-production road vehicles (the vocabulary part) [2] | Edition 2, published December 2018. "To be revised" (90.92); the next version ISO/DIS 26262-1 is under development |
| ISO 21448:2022 (SOTIF) | Safety of the intended functionality (SOTIF): absence of unreasonable risk from hazards caused by functional insufficiencies (specification insufficiencies or performance insufficiencies of E/E elements). Applies where situational awareness comes from complex sensors and processing [3] | Edition 1, published June 2022. "To be revised" (90.92). The earlier ISO/PAS 21448:2019 is withdrawn |
| ISO/PAS 8800:2024 | Road vehicles: safety and AI. Applies to safety-related systems with E/E systems using AI technology and addresses vehicle-level risk of undesired safety-related behaviour from output insufficiencies, systematic errors and random hardware errors of AI elements [4] | Published December 2024. A PAS (publicly available specification), not an International Standard |
| ISO/TS 5083:2025 | Safety for automated driving systems: design, verification and validation. Guidance on achieving and demonstrating safety of level 3 and 4 ADS features, also outlining cybersecurity considerations [5] | Edition 1, published April 2025. "To be revised" (90.92), with ISO/WD TS 5083 under development as successor. Replaces ISO/TR 4804:2020 |
| ISO 34502:2022 | A scenario-based safety evaluation framework for ADS, applied during development, for limited access highways. Does not address misuse, human-machine interface or cybersecurity [6] | Edition 1, published November 2022. ISO/TC 22/SC 33 |
All Sourced (a summary of abstracts, editions and statuses on ISO pages; the texts were not read and no requirements are inferred).
The abstract of ISO/PAS 8800 says it addresses vehicle-level safety risk from random hardware errors, alongside output insufficiencies and systematic errors of AI elements.Sourced[Ref. 4] Behind hardware errors lie materials and process issues such as the reliability of semiconductor memory and logic, thermal and mechanical stress in packages, and ageing of materials (our commentary; PAS 8800 does not discuss particular materials).
The heat, power and memory constraints of running AI inference on an in-vehicle computer follow the same pattern as in our explainer on edge and on-device AI, and sensors such as LiDAR are in our LiDAR explainer. This article covers the safety argument and evaluation framework that sits on top of them (our positioning).
6. Regulation by stage and date: adoption, entry into force and expectations
Regulation moves through separate stages of proposal, adoption (agreement) and entry into force (application), and differs by jurisdiction. Items confirmed in official material are organized below by stage and date (checked 15 October 2026).
| Jurisdiction / body | Content (as stated in official material) | Stage and date |
|---|---|---|
| UN WP.29 (per Japan's MLIT) | 2020: agreement on the first international standard for passenger-car automated driving systems (traffic-jam use at or below 60 km/h, limited to lane keeping) [8] | Adopted (agreed): MLIT announcement of 25 June 2020 |
| UN WP.29 (per Japan's MLIT) | 23 to 26 June 2026: agreement on an international standard for automated driving systems including levels 3 and 4, with requirements for vehicle safety such as obeying traffic rules, avoiding collisions and stopping safely on malfunction, plus the manufacturer's organization and identification and correction of faults through monitoring of vehicles in service [7] | Adopted (agreed): MLIT announcement of 26 June 2026. Entry into force around January 2027 is an expectation, Not yet confirmed |
| EU | Implementing Regulation (EU) 2022/1426: type-approval of the ADS of fully automated vehicles of categories M and N, for use cases in a predefined area, on a predefined route with fixed start and end (hub-to-hub) and automated valet parking [9] | Adopted 5 August 2022; published in the Official Journal 26 August 2022; in force on the twentieth day after publication |
| Japan | An amendment to the Road Traffic Act created a permit system (from prefectural public safety commissions) for driverless operation equivalent to SAE level 4, called "specified automated operation" (National Police Agency) [10] | In force: April 2023 (as stated on the National Police Agency page) |
| United States (NHTSA) | Standing General Order: requires named manufacturers and operators to report certain crashes involving ADS and SAE level 2 ADAS; for ADS, a crash is reportable if ADS was in use within 30 seconds of it and it caused certain property damage or injury [11] | In force: first issued 2021, amended in 2021, 2023 and 2025 (as stated on the NHTSA page) |
All Sourced (a summary of each official page). Other jurisdictions such as China are not given because official material could not be confirmed in this article's research.
7. On-road data and "how many miles it takes to show it"
In the United States, NHTSA's Standing General Order collects reports of crashes involving ADS, and NHTSA's page cautions that understanding the limitations of these data is crucial for accurate interpretation.Sourced[Ref. 11] As an example in which an operator itself analyzed safety using these reports, the paper by Kusano et al. (by Waymo authors, Traffic Injury Prevention, 2024) reports, over about 7.14 million driverless ride-hailing miles through the end of October 2023 in Phoenix, San Francisco and Los Angeles, a rate of any-injury-reported crashed vehicles of 0.6 per million miles for the ADS against 2.80 for the human benchmark, among other results. The authors also say that, given imprecision in the benchmark and multiple possible sources of underreporting that bias it, caution is needed in interpretation and the results should be used as "a directional and continuous confidence growth indicator", together with other methods, in a safety-case approach.Sourced[Ref. 14]
RAND (Kalra and Paddock, 12 April 2016) calculated that, because fatalities and injuries are rare compared with miles driven, showing the safety of fully autonomous vehicles statistically clearly would take hundreds of millions and sometimes hundreds of billions of miles, and tens or hundreds of years for existing fleets, concluding that driving alone is not enough and new methods of demonstration are needed.Sourced[Ref. 13]
Our calculation Idea: assume events (such as fatal crashes) occur independently at a constant rate (a Poisson process). If no event occurs in n miles, the 95% upper confidence limit on the true rate is about 3 / n (the rule of three). To bring it down to a human rate R or below needs n >= 3 / R miles with zero events.
Fatalities: the U.S. 2024 fatality rate is 1.19 per 100 million miles (NHTSA).Sourced[Ref. 12] 3 / (1.19 x 10^-8) = about 252 million miles. For a fleet driving 10 million miles a year (assumed) that is about 25 years.
Crashes with any injury reported (human benchmark 2.80 per million miles, the all-locations figure of Kusano et al.)Sourced[Ref. 14]: about 1.07 million miles. Police-reported crashes (4.68): about 0.64 million miles. Because such events are roughly 100 to 200 times more frequent, the distance needed is far shorter.
Assumptions and limits: this is a best-case lower bound with zero events; if events occur, the distance needed is longer. The assumptions of a constant rate and independence do not hold across regions, weather, time of day and vehicle updates. There is also uncertainty in how the human rate is measured (reporting, region). "At or below the human rate" here is not proof that a crash rate is low but a guide to the minimum distance needed for the statement to be statistically supportable. It does not evaluate the safety of any individual operator.
The causes of accidents should be discussed on the basis of verifiable primary material such as official investigation reports and court records, and cannot be asserted from news or video. This article does not take up individual accidents and does not evaluate, recommend or blame any company or product. It only shows the reporting mechanisms (such as NHTSA's General Order) and the limits of the data.
Materials life testing too has the difficulty of extrapolating from tests under limited conditions to real-use life (see our explainer on battery evaluation and degradation, among others). The same applies to evaluating autonomous driving: whether results from a particular region, weather, period and vehicle can be extrapolated to other conditions is the issue. That datasets are captured in limited regions (nuScenes in Boston and Singapore)Sourced[Ref. 15] and that on-road data concentrate in particular citiesSourced[Ref. 14] are examples. Not comparing bare numbers without their conditions is a way of reading shared with materials evaluation (our commentary).
Changes in the performance of sensor windows, covers and lenses (LiDAR, camera, radar) from dirt, water drops and temperature may be one of the factors that set ODD conditions (our commentary, unsourced). How LiDAR works is covered in our LiDAR explainer.
8. Limits, and what could not be confirmed
- UNECE's official pages: the June 2026 WP.29 agreement was confirmed from Japan's MLIT announcement (26 June 2026). UNECE's official pages could not be accessed automatically because of bot detection at the time of checking, and their text could not be read. The formal name and number of the instrument (UN Regulation or global technical regulation), its clauses and how each country brings it into force are therefore not given. The expected entry into force (around January 2027) is MLIT's expectation.
- Extent of operations and company comparisons: which companies operate which services in which cities is not covered. Operators' safety data appear only as one example, the operator's own report (Kusano et al.), with no comparison among companies and no assessment of safety.
- Texts of standards: for ISO 26262, 21448, PAS 8800, TS 5083 and 34502 only abstracts, editions and statuses were confirmed; the texts are paid and not read, and no requirements are inferred. For SAE J3016_202609 too the definitions were not read; only the descriptors shown on the page are summarized.
- Other jurisdictions and technologies: Chinese regulation, driver monitoring (levels 2 and 3), remote operation and monitoring, cybersecurity (such as UN R155) and links to vehicle electrification and batteries are not covered. See the LiDAR explainer for sensors and the edge and on-device AI explainer for in-vehicle computing.
- Benchmark figures: individual accuracy figures for datasets and methods are not shown because settings do not align and would imply a ranking. "First", "largest" and "state of the art" are the authors' claims.
- The level (SAE) and the operating conditions (ODD) are separate. SAE J3016 was revised on 20 September 2026 (J3016_202609) and the descriptors changed, but descriptors are not definitions.Sourced
- Regulation separates adoption from entry into force. WP.29 agreed an ADS standard in June 2026 with entry into force expected around January 2027 (not yet confirmed); the EU has had its rule since 2022 and Japan its permit system since April 2023.Sourced
- Log-replay numbers do not mean good closed-loop driving. Numbers from different evaluation levels cannot be converted.Sourced
- Safety cannot be shown by distance alone. By the rule of three, the fatality level alone needs about 252 million miles, and an argument combining standards (functional safety, SOTIF, AI safety, ADS safety and scenario evaluation) with on-road data is needed.Our calculation
- Causes of individual accidents are not guessed at, and no company is recommended or blamed. Operators' self-reports are kept apart from independent verification.
9. How to read evaluations and standards
Evaluating autonomous driving rests on four separate frameworks: (1) the performance of perception, prediction and planning (datasets and simulation), (2) on-road safety (real data such as crash rates compared with human baselines), (3) the safety argument (a safety case following standards) and (4) regulatory compliance (type-approval or permits). Benchmark numbers change with who ran them, the settings and the level, and regulation and standards differ in nature by whether they are legally binding.
| Item | Representative benchmarks and methods (name, source) | Standards, guidance and regulation | How to read it |
|---|---|---|---|
| Perception (detection and tracking) | nuScenes (3D detection and tracking metrics) [15] and the Waymo Open Dataset (2D and 3D detection and tracking) [16] Sourced | ISO 21448:2022 (SOTIF: risk from functional insufficiencies of functions whose situational awareness derives from complex sensors and processing) [3] Sourced | Dataset regions and sensors are limited. Do not extrapolate accuracy figures beyond the ODD |
| Prediction and planning | Log replay (open loop, e.g. nuScenes), NAVSIM (non-reactive) [18], nuPlan [17], and Bench2Drive and CARLA (closed loop) [19, 20] Sourced | ISO 34502:2022 (scenario-based safety evaluation framework; limited access highways) [6] Sourced | Log-replay metrics may not comprehensively assess planning quality (Li et al.) [23]. Numbers from different levels cannot be converted |
| On-road safety | Reports under NHTSA's General Order [11], Kusano et al. (an operator's own analysis) [14] and RAND's statistical analysis [13] Sourced | None found (an international standard deciding pass or fail on on-road safety) | How the human baseline is measured and underreporting can sway conclusions (the authors' own caution) [14]. Keep independent verification apart from operators' self-reports |
| Safety argument | None found (published safety cases for individual vehicles) | ISO 26262-1:2018 (functional safety) [2], ISO/PAS 8800:2024 (AI safety) [4] and ISO/TS 5083:2025 (ADS safety) [5]; each is under revision or has a successor in development, or is a PAS or TS (informative guidance) Sourced | Texts are paid and not read. The PAS 8800 abstract says it describes safety-related properties of AI systems that can be used to construct a convincing safety assurance claim for the absence of unreasonable risk. Do not infer requirements |
| Regulatory compliance | None found (type-approval results for individual vehicles) | EU Implementing Regulation 2022/1426 [9] and Japan's specified-automated-operation permit system [10] Sourced. The WP.29 ADS international standard: agreed, entry into force expected around January 2027 [7] Not yet confirmed | Regulation is legally binding and limited in scope (EU: predefined area, hub-to-hub and parking). It differs by country |
| Terminology and levels | None found | SAE J3016_202609 (current, 20 September 2026) and J3016_202104 (historical) [1]. ISO/SAE PAS 22736, referred to in the abstracts of ISO/TS 5083 and 34502 Sourced | Descriptors are not definitions. Do not mix them with level names from older editions |
Category tags appear in each cell. The SAE, ISO and NHTSA pages were checked in a browser on 15 October 2026, and statements of Japan's MLIT and National Police Agency and of the EU (EUR-Lex) were also checked. The arrangement of the table is our own.
Three points on how to read these.
- Who measured it and at which level: numbers mean different things in log replay, non-reactive simulation, closed loop and on-road driving, and an operator's own analysis differs from independent verification. "First", "largest" and "state of the art" are the authors' claims.
- Regulation by stage and date: agreement (adoption) and entry into force (application) are different, and expected dates are not yet confirmed. Some systems, as in the EU and Japan, are limited in use case and conditions.
- Standards are often guidance: ISO/PAS 8800 is a publicly available specification and ISO/TS 5083 a technical specification, both lighter in status than an International Standard, and revisions or successors are in development. Their texts were not read, so whether any part is a requirement is not asserted.
10. Glossary
- SAE levels
- Levels 0 to 5 of driving automation, defined in J3016.
- DDT
- Dynamic driving task: the real-time functions needed to operate a vehicle (steering, speed control, monitoring surroundings and so on).
- ODD
- Operational design domain: the range of conditions in which a system is designed to operate.
- ADS
- Automated driving system: hardware and software that perform the entire DDT on a sustained basis within an ODD.
- Open loop / closed loop
- Evaluated by replaying logs / evaluated where the vehicle's actions change the next situation.
- End-to-end
- A structure linking sensors to planning through learned networks.
- Functional safety
- Managing hazards from faults and malfunctions of E/E systems (ISO 26262).
- SOTIF
- Safety of the intended functionality: no unreasonable risk from functional insufficiencies (ISO 21448).
- PAS / TS
- Publicly available specification / technical specification: ISO document types lighter than an International Standard.
- WP.29
- The UN World Forum for Harmonization of Vehicle Regulations, where international vehicle regulations are made.
- Rule of three
- A guide that, with zero events, the 95% upper confidence limit is about 3 / n.
- SGO
- NHTSA's Standing General Order requiring crash reports for ADS and level 2 systems.
11. References
- SAE International "J3016_202609: Taxonomy and Definitions for Terms Related to Driving Automation Systems for On-Road Motor Vehicles" (current, revised 20 September 2026; the change of the short descriptors and the note that definitions are in Sections 4 and 5; J3016_202104 is historical; checked 15 October 2026) — sae.org/standards/j3016_202609-taxonomy-definitions-terms...
- ISO "ISO 26262-1:2018 Road vehicles — Functional safety — Part 1: Vocabulary" (edition 2, December 2018; to be revised, ISO/DIS 26262-1 under development) — iso.org/standard/68383.html
- ISO "ISO 21448:2022 Road vehicles — Safety of the intended functionality" (edition 1, June 2022; to be revised) — iso.org/standard/77490.html
- ISO "ISO/PAS 8800:2024 Road vehicles — Safety and artificial intelligence" (December 2024) — iso.org/standard/83303.html
- ISO "ISO/TS 5083:2025 Road vehicles — Safety for automated driving systems — Design, verification and validation" (edition 1, April 2025; to be revised, with ISO/WD TS 5083 as successor) — iso.org/standard/81920.html
- ISO "ISO 34502:2022 Road vehicles — Test scenarios for automated driving systems — Scenario based safety evaluation framework" (edition 1, November 2022) — iso.org/standard/78951.html
- Ministry of Land, Infrastructure, Transport and Tourism (Japan) "International standard for automated driving systems, the world's first, led by Japan, agreed" press release (26 June 2026; WP.29 on 23 to 26 June 2026, levels 3 and 4, entry into force expected around January 2027; in Japanese) — mlit.go.jp/report/press/jidosha10_hh_000350.html
- Ministry of Land, Infrastructure, Transport and Tourism (Japan) "International standard on automated driving systems (level 3) established for the first time" press release (25 June 2020; WP.29 181st session, up to 60 km/h, lane keeping; in Japanese) — mlit.go.jp/report/press/jidosha07_hh_000343.html
- European Commission Commission Implementing Regulation (EU) 2022/1426 of 5 August 2022 (type-approval of the ADS of fully automated vehicles; OJ L 221/1, 26 August 2022) — eur-lex.europa.eu/legal-content/EN/TXT/HTML/?uri=CELEX:32...
- National Police Agency (Japan) "Self-driving" page (creation of the permit system for specified automated operation equivalent to level 4, in force April 2023; checked 15 October 2026; in Japanese) — npa.go.jp/bureau/traffic/selfdriving/index.html
- NHTSA "Standing General Order on Crash Reporting" (ADS and level 2 ADAS; first issued 2021, amended 2021, 2023 and 2025; reporting requirements; data limitations; checked 15 October 2026) — nhtsa.gov/laws-regulations/standing-general-order-crash-r...
- NHTSA "Research Note: Overview of Motor Vehicle Traffic Crashes in 2024", DOT HS 813 791 (April 2026) (39,254 deaths in 2024; fatality rate of 1.19 per 100 million VMT) — crashstats.nhtsa.dot.gov/Api/Public/ViewPublication/813791
- RAND Kalra N., Paddock S. M., "Driving to Safety: How Many Miles of Driving Would It Take to Demonstrate Autonomous Vehicle Reliability?", RR-1478 (12 April 2016) — rand.org/pubs/research_reports/RR1478.html
- Kusano K. D. et al. "Comparison of Waymo rider-only crash data to human benchmarks at 7.1 million miles", Traffic Injury Prevention (2024), DOI 10.1080/15389588.2024.2380786, arXiv 2312.12675 (a report by the operator's authors) — arxiv.org/abs/2312.12675
- Caesar H. et al. "nuScenes: A multimodal dataset for autonomous driving", arXiv 1903.11027 (2019) — arxiv.org/abs/1903.11027
- Sun P. et al. "Scalability in Perception for Autonomous Driving: Waymo Open Dataset", arXiv 1912.04838 (2019) — arxiv.org/abs/1912.04838
- Caesar H. et al. "NuPlan: A closed-loop ML-based planning benchmark for autonomous vehicles", arXiv 2106.11810 (2021) — arxiv.org/abs/2106.11810
- Dauner D. et al. "NAVSIM: Data-Driven Non-Reactive Autonomous Vehicle Simulation and Benchmarking", arXiv 2406.15349 (2024) — arxiv.org/abs/2406.15349
- Jia X. et al. "Bench2Drive: Towards Multi-Ability Benchmarking of Closed-Loop End-To-End Autonomous Driving", arXiv 2406.03877 (2024) — arxiv.org/abs/2406.03877
- Dosovitskiy A. et al. "CARLA: An Open Urban Driving Simulator", arXiv 1711.03938 (2017) — arxiv.org/abs/1711.03938
- Hu Y. et al. "Planning-oriented Autonomous Driving" (UniAD), arXiv 2212.10156 (2022) — arxiv.org/abs/2212.10156
- Hwang J.-J. et al. (Waymo) "EMMA: End-to-End Multimodal Model for Autonomous Driving", arXiv 2410.23262 (2024) — arxiv.org/abs/2410.23262
- Li Z. et al. "Is Ego Status All You Need for Open-Loop End-to-End Autonomous Driving?", arXiv 2312.03031 (2023) — arxiv.org/abs/2312.03031
- Chen L. et al. "End-to-end Autonomous Driving: Challenges and Frontiers", arXiv 2306.16927 (2023) — arxiv.org/abs/2306.16927
12. Claim-to-source audit
| Claim in the text | Basis | Category |
|---|---|---|
| SAE J3016_202609: current (revised 20 September 2026), the change of the short level descriptors (levels 0 to 5), descriptors are not definitions and definitions are in Sections 4 and 5, the level is set by the feature engaged, and J3016_202104 is historical | Reference 1 https://www.sae.org/standards/j3016_202609-taxonomy-definitions-terms-related-driving-automation-systems-road-motor-vehicles | Sourced |
| ISO 26262-1:2018 (functional safety, edition 2, December 2018, to be revised, next version ISO/DIS 26262-1 in development) | Reference 2 https://www.iso.org/standard/68383.html | Sourced |
| ISO 21448:2022 (SOTIF, edition 1, June 2022, to be revised, PAS 21448:2019 withdrawn) and its abstract stating it applies where situational awareness derives from complex sensors and processing | Reference 3 https://www.iso.org/standard/77490.html | Sourced |
| ISO/PAS 8800:2024 (December 2024; addresses output insufficiencies, systematic errors and random hardware errors of AI elements; describes properties for constructing a safety assurance claim) | Reference 4 https://www.iso.org/standard/83303.html | Sourced |
| ISO/TS 5083:2025 (April 2025; guidance on design, verification and validation of level 3 and 4 ADS; to be revised, ISO/WD TS 5083 as successor; replaces ISO/TR 4804:2020) | Reference 5 https://www.iso.org/standard/81920.html | Sourced |
| ISO 34502:2022 (November 2022; scenario-based safety evaluation framework for ADS, applies to limited access highways, does not address misuse, HMI or cybersecurity) | Reference 6 https://www.iso.org/standard/78951.html | Sourced |
| MLIT (26 June 2026): at the WP.29 session of 23 to 26 June 2026 an international standard for automated driving systems including levels 3 and 4 was agreed; requirements (obeying traffic rules, collision avoidance, safe stop on malfunction, manufacturer's organization, identification and correction of faults through monitoring); entry into force expected around January 2027 | Reference 7 https://www.mlit.go.jp/report/press/jidosha10_hh_000350.html | Sourced |
| The expected entry into force around January 2027 | Reference 7 https://www.mlit.go.jp/report/press/jidosha10_hh_000350.html | Not yet confirmed |
| MLIT (25 June 2020): at the 181st WP.29 session the first international standard for passenger-car automated driving systems was agreed (traffic-jam use at or below 60 km/h, limited to lane keeping) | Reference 8 https://www.mlit.go.jp/report/press/jidosha07_hh_000343.html | Sourced |
| EU Implementing Regulation 2022/1426: 5 August 2022, OJ L 221/1 (26 August 2022), type-approval of the ADS of fully automated vehicles (M and N), use cases (predefined area, hub-to-hub, automated valet parking), definitions of ADS and ODD, in force 20 days after publication | Reference 9 https://eur-lex.europa.eu/legal-content/EN/TXT/HTML/?uri=CELEX:32022R1426 | Sourced |
| National Police Agency: creation of a permit system for specified automated operation equivalent to level 4, permits from prefectural public safety commissions, in force April 2023 | Reference 10 https://www.npa.go.jp/bureau/traffic/selfdriving/index.html | Sourced |
| NHTSA General Order: crash reports for ADS and level 2 ADAS, first issued 2021 and amended 2021, 2023 and 2025, ADS reportable if in use within 30 seconds with certain property damage or injury, caution on data limitations | Reference 11 https://www.nhtsa.gov/laws-regulations/standing-general-order-crash-reporting | Sourced |
| NHTSA (April 2026): 39,254 deaths in 2024 (41,025 in 2023), fatality rate of 1.19 per 100 million VMT (1.26 in 2023), VMT of 3,294 billion | Reference 12 https://crashstats.nhtsa.dot.gov/Api/Public/ViewPublication/813791 | Sourced |
| RAND (12 April 2016): hundreds of millions to hundreds of billions of miles, tens to hundreds of years for existing fleets, driving alone cannot show safety and new methods are needed | Reference 13 https://www.rand.org/pubs/research_reports/RR1478.html | Sourced |
| Kusano et al.: about 7.14 million miles (through end of October 2023), any-injury-reported crash rates of 0.6 for ADS and 2.80 for humans per million miles, police-reported 2.1 and 4.68, caution about benchmark imprecision and underreporting bias, to be used as a directional indicator within a safety case (a report by the operator's authors) | Reference 14 https://arxiv.org/abs/2312.12675 | Sourced |
| nuScenes: 6 cameras, 5 radars and 1 lidar, 1,000 scenes, 23 classes and 8 attributes | Reference 15 https://arxiv.org/abs/1903.11027 | Sourced |
| Waymo Open Dataset: 1,150 scenes, synchronized and calibrated LiDAR and camera, 15x more diverse (authors' claim) | Reference 16 https://arxiv.org/abs/1912.04838 | Sourced |
| nuPlan: 1,500 hours, four cities, closed-loop simulator, "world's first" (authors' claim) | Reference 17 https://arxiv.org/abs/2106.11810 | Sourced |
| NAVSIM: a non-reactive simulator between open- and closed-loop evaluation, with metrics such as progress and time to collision | Reference 18 https://arxiv.org/abs/2406.15349 | Sourced |
| Bench2Drive: a multi-ability closed-loop benchmark for end-to-end methods, addressing issues with open-loop evaluation and fixed-route scores | Reference 19 https://arxiv.org/abs/2406.03877 | Sourced |
| CARLA: an open urban driving simulator | Reference 20 https://arxiv.org/abs/1711.03938 | Sourced |
| UniAD: a framework bringing perception, prediction and planning into one network oriented toward planning, reported to outperform earlier work on nuScenes | Reference 21 https://arxiv.org/abs/2212.10156 | Sourced |
| EMMA: a multimodal-LLM-based model outputting planner trajectories, objects and road graphs from camera images, with results on nuScenes and the Waymo Open Motion Dataset | Reference 22 https://arxiv.org/abs/2410.23262 | Sourced |
| Li et al.: reliance on ego status in open-loop evaluation on nuScenes, metrics possibly not assessing planning quality comprehensively, and the suggestion of a cautious reassessment | Reference 23 https://arxiv.org/abs/2312.03031 | Sourced |
| A survey of the challenges and frontiers of end-to-end driving | Reference 24 https://arxiv.org/abs/2306.16927 | Sourced |
| Distances needed by the rule of three (fatality: 3 / (1.19 x 10^-8) = about 252 million miles, about 25 years at an assumed 10 million miles a year; any-injury crashes: about 1.07 million miles; police-reported crashes: about 0.64 million miles) | Our calculation. A best-case lower bound assuming a constant, independent rate and zero events, not proof of safety. Human rates are the values of NHTSA and Kusano et al. | Our calculation |
| The links of "the AI safety standard also covers random hardware errors" to materials and processes, "extrapolating evaluations has the same pitfalls as materials life testing", and the view that dirt and temperature on sensor windows and lenses may affect the ODD (no source) | This article's organization and commentary based on published material, not views stated by the organizations | Commentary |
| The text of UNECE's official pages, texts of standards, comparisons or evaluations of specific operators, and causes of individual accidents | Not confirmed within this article's research, or deliberately not covered, and therefore not given; this article's note | Commentary |
Last updated: 15 October 2026. Sources are limited to primary material (SAE and ISO pages, announcements of Japan's MLIT and National Police Agency, EUR-Lex, NHTSA, RAND, and papers). The text of UNECE's official pages, the texts of standards, comparisons or evaluations of specific operators and causes of individual accidents could not be confirmed or are deliberately not covered, and are not given. Expected regulatory dates are "not yet confirmed". Figures 2 to 4 and 6 are vector drawings, Figure 5 includes our calculation, and Figures 1 and 7 are AI-image placeholders only.