Key Findings
The proposed ANFIS-based framework significantly enhances safety margins compared to Time-to-Collision (TTC) baselines. In simulation, the system increased the minimum two-dimensional clearance from 2.08 to 4.82 m and reduced maximum deceleration demand from 4.92 to 2.34 m/s². Across 1,000 randomized Monte Carlo simulations—incorporating variations in sensor noise, road friction, vehicle speeds, and cut-in timing—no collisions occurred. The system recorded a near-miss rate of 0.30% and a false-alarm rate of 1.20%, with a mean computational execution time of 1.42 ms, well within the 10-ms control-cycle budget.
Technical Details
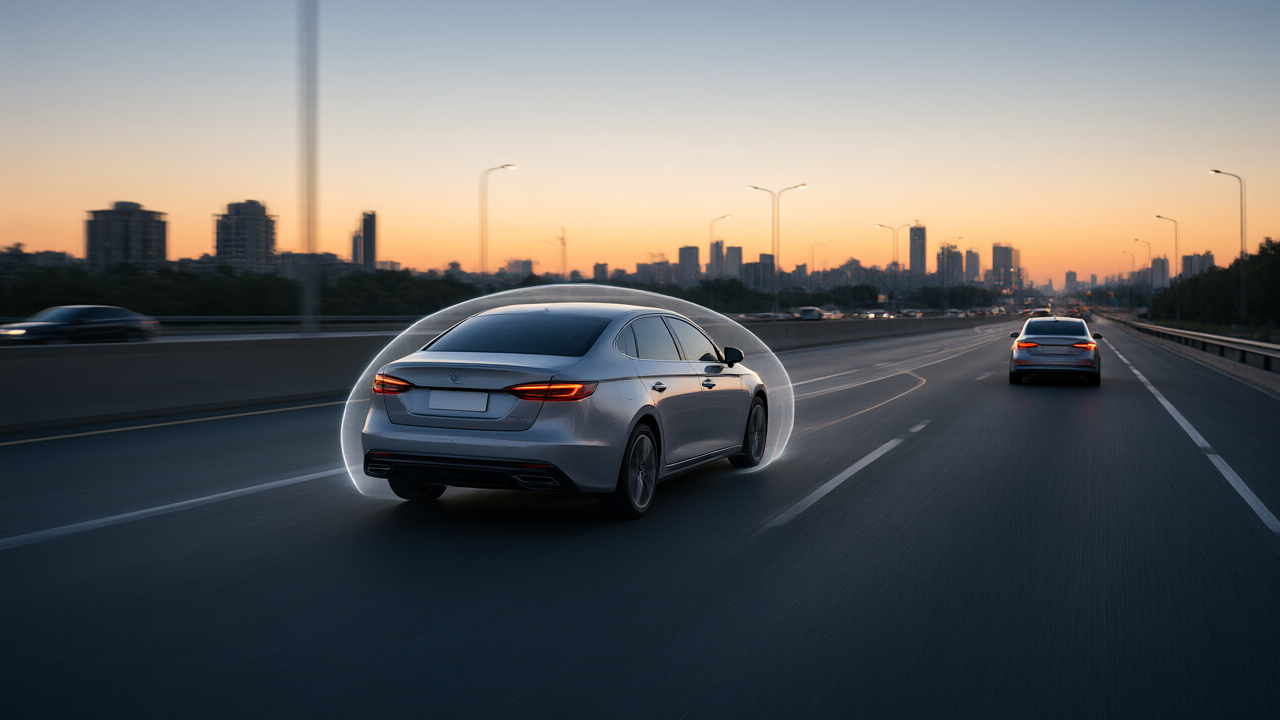
The framework utilizes an adaptive neuro-fuzzy inference system to generate a continuous risk index (0 to 1) by combining minimum inter-vehicle gaps and normalized longitudinal braking demand. This index is integrated into a two-phase decision mechanism that includes:
- Multi-vehicle threat assessment and region-dependent maneuver cancellation.
- Quintic Bézier trajectory replanning for smooth lateral transitions.
- Driver takeover supervision for Level-3 autonomy.
Performance was validated using high-fidelity SCANeR/ReScan and MATLAB/Simulink co-simulations against baselines including deceleration-demand, time-headway, and static Mamdani fuzzy logic.
Background & Context
Lane-change (LC) maneuvers in SAE Level 3 autonomous driving are complex due to the coupling of longitudinal braking and evolving gaps between multiple vehicles. Conventional deterministic rule-based structures and static threshold models (such as MOBIL) often rely on binary safety boundaries. These rigid architectures frequently result in boundary chattering, delayed abort triggers, or conservative over-braking, as they fail to capture the continuous stochastic gradient of conflict severity found in real-world highway environments.
Significance & Outlook
The integration of neuro-fuzzy risk assessment allows for earlier hazard detection and larger safety margins without sacrificing the rule-based interpretability required for autonomous systems. While simulation results demonstrate high robustness and low computational cost, the researchers note that hardware-in-the-loop and real-vehicle testing are necessary to validate performance beyond simulated conditions.
Source: https://www.frontiersin.org/articles/10.3389/fnbot.2026.1918469
Get our weekly technology intelligence — free
Receive an infographic that lets you judge at a glance whether each field’s analysis report is worth reading.
Subscribe Free — Weekly Tech Intelligence
By subscribing, you’ll receive Troy-Technical’s weekly technology intelligence newsletter.
- Your email and selected fields are used only to deliver the newsletter.
- We never share your information with third parties.
- You can unsubscribe anytime via the link in each email.
See our Privacy Policy for details.
Takes about a minute · Unsubscribe anytime