Key Findings
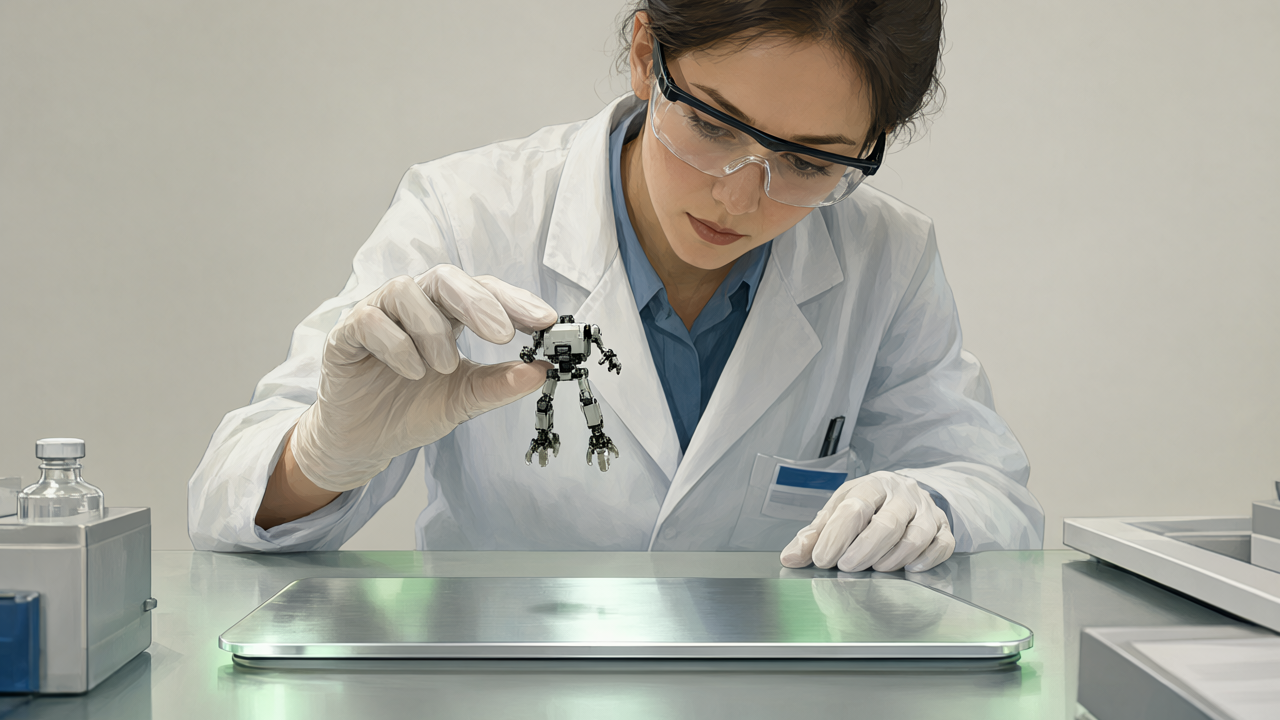
A research team at Fudan University in China has developed a groundbreaking technology for micro-robots that enables them to generate electrical power electrochemically by traversing metal surfaces. This is achieved through a thin, 135 µm polymer gel membrane attached to the robots’ feet. This system eliminates the need for heavy onboard batteries, allowing the robots to directly ‘harvest’ energy from active metallic surfaces such as aluminum, zinc, and silicon, thereby significantly enhancing the autonomous and continuous operation of microrobots.
Technical / Clinical Details
- Self-Powering Mechanism: The specialized gel membrane on the robot’s feet functions as an aqueous electrolyte when in contact with active metal surfaces, initiating an electrochemical reaction that generates an electric current. This process utilizes redox reactions of the metals, differentiating it from existing energy harvesting technologies like triboelectric nanogenerators (TENGs).
- Lightweight and Efficient: Compared to traditional battery systems, the gel membrane is exceptionally thin and lightweight, substantially reducing the overall robot mass. This reduction improves the microrobot’s mobility, payload capacity, and operational duration. The elimination of battery recharging or replacement also streamlines operational efficiency.
- Versatility Across Metal Surfaces: The ability to generate power from various common metal surfaces, including aluminum, zinc, and silicon, suggests broad applicability across diverse industrial and natural environments. This provides a distinct advantage for autonomous operations in settings rich in metallic structures.
Background & Context
One of the primary challenges for micro-robots and small-scale robotics has been securing a sustainable power source. The limited size and weight of onboard batteries directly constrained operational time and performance. Fudan University’s research addresses this fundamental issue by applying the principle of ‘energy harvesting’ directly from the environment. This breakthrough enables autonomous and long-duration missions for microrobots in hazardous or inaccessible environments, opening new avenues for surveillance, inspection, and reconnaissance applications.
Strategic Significance & Outlook
This foot-mounted gel membrane power generation technology has the potential to dramatically expand the application scope of microrobots. It could prove invaluable for missions requiring continuous power supply, such as searching for survivors in disaster zones, inspecting pipelines within nuclear reactors, monitoring contaminated areas, and even powering in-vivo diagnostic robots in the medical field. Future advancements are expected to further improve the power generation efficiency across a wider range of surfaces and environments, contributing to the realization of truly autonomous micro-robot networks. This represents a transformative step in power management paradigms for robotics.
Source: https://newatlas.com/robotics/robot-harvests-power-skin-feet-membrane/
Get our weekly technology intelligence — free
Receive an infographic that lets you judge at a glance whether each field’s analysis report is worth reading.
Subscribe Free — Weekly Tech Intelligence
By subscribing, you’ll receive Troy-Technical’s weekly technology intelligence newsletter.
- Your email and selected fields are used only to deliver the newsletter.
- We never share your information with third parties.
- You can unsubscribe anytime via the link in each email.
See our Privacy Policy for details.
Takes about a minute · Unsubscribe anytime